Member Login

2025 Annual ACC Awards

ACC Annual Awards 2025: Celebrating Excellence and Collaboration

The Australian Cobotics Centre proudly celebrated the outstanding achievements of our researchers, collaborators, and supporters at the 2025 Annual Symposium. These awards highlight the dedication, creativity, and impact of our community.

Research Achievement

  • Munia Ahamed – For high-quality publications and impactful industry outcomes, including award-winning work on defect management and leading the Cook Medical quality framework validation project.
  • Jagannatha Pyaraka – For multiple first-author papers on human-object interaction and humanoid navigation, alongside significant contributions to industry projects and workshops.

Best Collaborative Research Output

  • InfraBuild Coil Raking Project Team
    Andrew (InfraBuild), Jagannatha Pyaraka, Danial Rizvi, Nadimul Haque, Sheila Sutjipto, Mariadas Roshan, Michelle Dunn, Chris McCarthy, Gavin Paul, Mats Isaksson, John McCormick, Teresa Vidal-Calleja, Jonathan Roberts.
    This team delivered an innovative coil-stack quality monitoring framework through multi-node collaboration, integrating robotics, computer vision, and manufacturing expertise for direct industry impact.

Industry Champion

  • James Dwyer – For exceptional industry engagement and design-led innovation, including a rapid prototype for Cook Medical and tools that advance teaching and collaborative projects.

Industry-Research Collaboration

  • Cook Medical Quality Framework Project Team
    Munia Ahamed, Mariadas Roshan, Nathalie Sick, Michelle Dunn, Matthias Guertler, Lee Clemon, Kettina Materna, Gareth Keen.
    Recognized for developing a systematic methodology to improve quality control in precision manufacturing, with strong multi-node collaboration and direct operational value for industry.

Contribution to Public Debate

  • Jasper Vermeulen – For thought leadership and active engagement in public discussions, enriching societal understanding of ACC-related research.

Emerging Leader

  • Mariadas Roshan – For transforming Program 4 from “surviving” to “thriving” through new research projects, mentoring HDRs, and driving publications—all while meeting every deadline and seeking new opportunities.

Quiet Achievers

  • Valeria Macalupu – For stepping into Project 2.6 with Stryker, supporting HDRs, and initiating new research within her first year.
  • Nisar – For joining an editorial board, publishing a journal paper, and winning two best poster awards at ANZAM.
  • Zongyuan – For developing a robotic battery sanding proof-of-concept with Vaulta and supporting industry engagement for humanoid robotics.

Epic Centre Citizens

  • Müge Belek Fialho Teixeira – For championing HDR experience, promoting collaboration, and supporting cross-university engagement.
  • Mariadas Roshan – For embodying the Centre’s spirit through exceptional research, industry collaboration, and cross-program leadership.

Whoopsie Daisy

  • Jagannatha Pyaraka – For resilience in turning multiple journal rejections into high-impact publications and attracting industry interest through persistence and innovation.

Thought Leader

  • Penny Williams – For shaping conversations on ethical technology and future-of-work, regularly presenting at industry forums and panels.

Centre Supporter

  • Jasper Vermeulen – For being a KPI champion, sharing updates across programs, and fostering community within the Centre.


Celebrating Together

To close out another successful year, our team swapped robots for lawn bowls and enjoyed a fun afternoon of barefoot bowls—a perfect way to celebrate collaboration, innovation, and community spirit.

Congratulations to all our winners and thank you to everyone who contributed to making 2025 a year of impact and progress. Here’s to an even bigger and brighter 2026!

QUT Excolo! Grant for Prof Will Browne

Congratulations to Chief Investigator Professor Will Browne, whose project ASTRO has taken out the top spot as the 2025 Champion of QUT’s Excolo! pitching competition Grand Final, securing up to $100,000 in investment funding via the Industry Engagement Fund. ASTRO is an Upper Arm Active Stroke Rehabilitation Orthotic that aims to enhance post-stroke recovery while easing demand on healthcare systems.

QUT Excolo! is a pitching competition delivered by QUT’s Office of Industry Engagement: research teams are matched with a commercialisation coach, and participate in pitching workshops in collaboration with QUT Entrepreneurship.

Read more: QUT – News

52nd Computers and Industrial Engineering Conference (CIE52)

UTS PhD researcher, Munia Ahamed presented her paper at the 52nd International Conference on Computers and Industrial Engineering (CIE52) on 29th October.

Her paper, entitled A Computational Approach to Quality Dimension Implementation in Industry 4.0:
Integrating DMAIC with Statistical Analysis for Enhanced Defect Management was co-authored by: Nathalie Sick, Matthias Guertler, Mickey Clemon and Mariadas Capsran Roshan.

The paper focused on developing a computational approach for implementing Quality Dimensions in Industry 4.0, integrating DMAIC with statistical modelling to strengthen defect management decision-making.

ARC Discovery Project successes

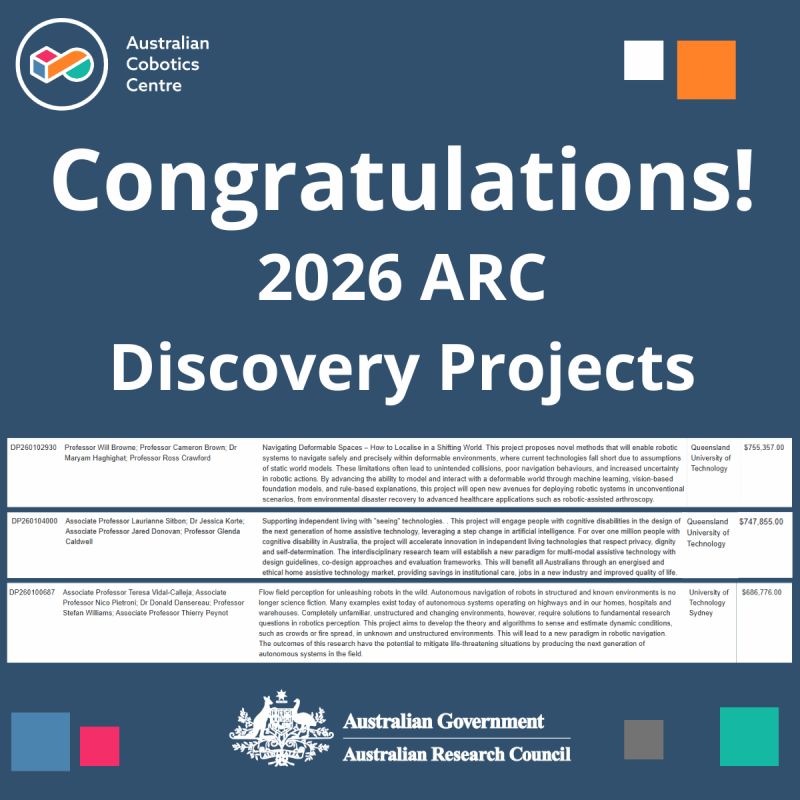
We’re excited to celebrate three ARC Discovery Project successes! These groundbreaking projects will advance robotics in deformable and unstructured environments and co-design assistive technologies that promote independence and dignity.

Congratulations to all our researchers for securing over $2.1M in funding!

  • Navigating Deformable Spaces – How to Localise in a Shifting World. Led by Prof Will Browne, Prof Cameron Brown, Dr Maryam Haghighat, and Prof Ross Crawford (QUT), this project will develop novel methods for robotic systems to operate safely and precisely in deformable environments—from disaster recovery zones to robotic-assisted surgery. Funding: $755,357
  • Supporting Independent Living with “Seeing” Technologies. Led by A/Prof Laurianne Sitbon, Dr Jessica Korte, A/Prof Jared Donovan, and Prof Glenda Caldwell (QUT), this project will co-design next-generation assistive technologies with people with cognitive disabilities, promoting independence, dignity, and privacy. Funding: $747,855
  • Robotic Navigation in Unstructured Environments. Led by Prof Teresa Vidal Calleja and team (UTS), this project will advance robotic perception and navigation in dynamic, unknown environments, enabling autonomous systems to respond to challenges like crowds or fire spread. Funding: $686,776


Read the full project list: Discovery Projects 2026 | Australian Research Council

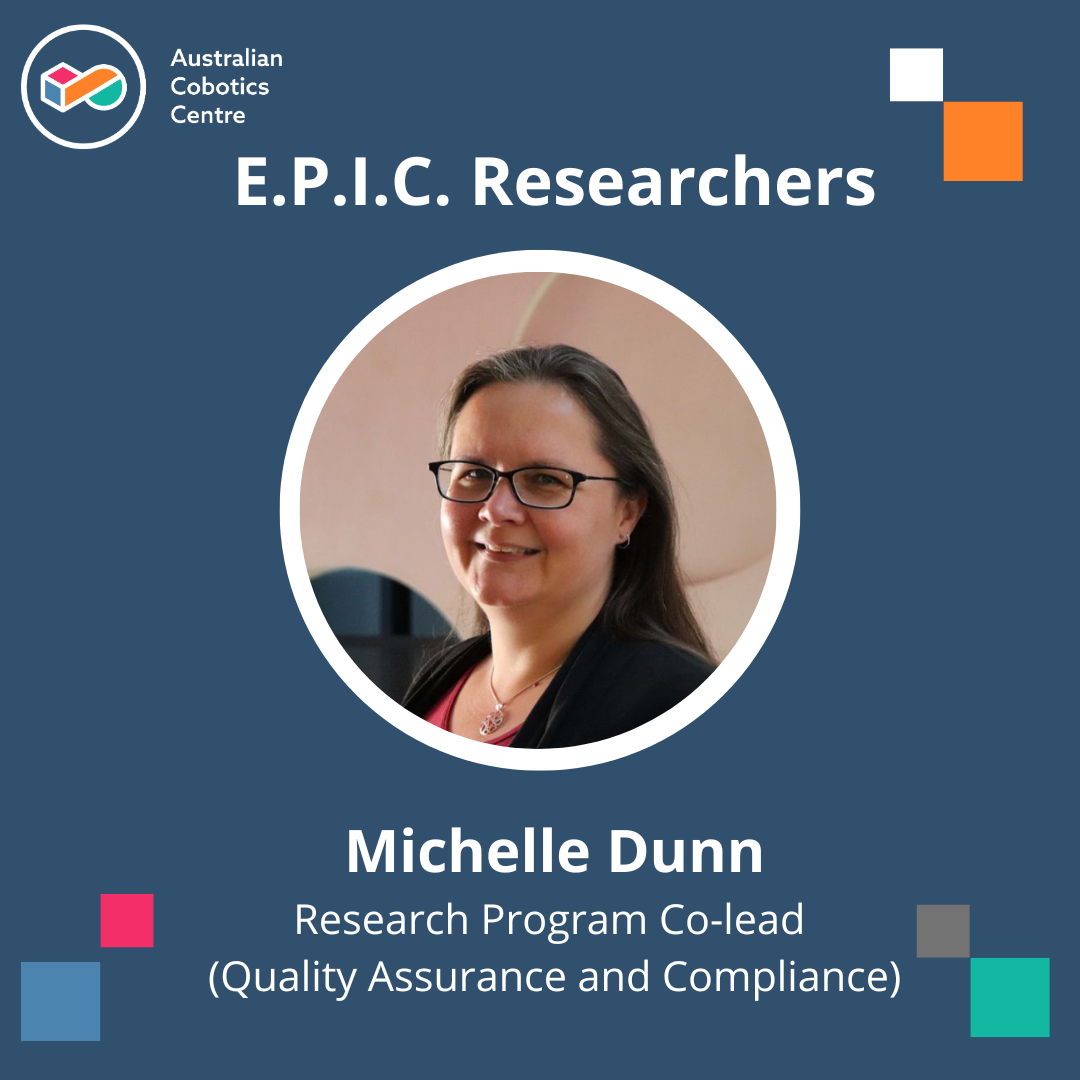
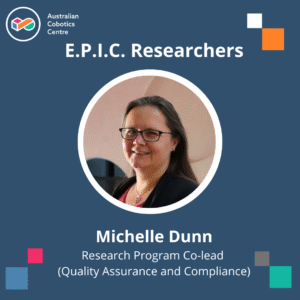
Meet our E.P.I.C. Researcher, Michelle Dunn

Michelle Dunn is a Research Program Co-lead in the Quality Assurance and Compliance Program where her research explores practical applications of robotics to improve everyday life. Her work spans manufacturing robotics and automation that make work easier, collaborative robotics that enable humans and robots to work safely side by side, and assistive technologies designed to support people in their daily activities.

We interviewed Michelle recently to find out more about why she does what she does.

Tell us a little about your role at the Australian Cobotics Centre.
What is your research focus and how does it contribute to the Centre’s mission?

I am the co-lead of Program 4 which looks at Quality Assurance and Compliance in Collaborative Robot scenarios. We focus on the outcomes of industrial and cobotic automation, ensuring that the solutions are working as intended.

What has been a highlight of your time with the Centre so far?
This could be a moment, a project, a collaboration, anything that stands out.

I particularly enjoyed the ACC 2024 Symposium in Brisbane. I think at the 3 year mark everyone in the centre was settled in, we knew each other, and we were showcasing some great solutions, so there was plenty of great conversations and ideas. I’m looking forward to the 2025 instalment.

What would you like your impact to be within the Centre and in the broader field of collaborative robotics?

Traditionally robots have focused on the three Ds – dirty, dangerous and dull jobs. Collaborative robots are designed to work with people, so we aren’t just looking at the 3-D jobs. Instead, we are looking at working with people in a broader variety of occupations. I’d like to see more cobots introduced into SMEs to assist with daily tasks and support small businesses – this is where we can make real impact.

What project or achievement are you most proud of in your career to date, and why?

What motivates me to do my job is having a direct impact on people’s lives – this is my goal in every project I’m part of. Some examples include: working as an automotive software engineer as my first job out of uni (there are cars in China that change gears based on the code that I wrote); my post-doc in vehicle crashworthiness (the value of which I unfortunately experienced firsthand); and educating literally thousands of students in Australia on how to design and build robots and become better engineers, which has flow-on effects to the whole community.

What do you find most rewarding about being part of the Australian Cobotics Centre?

The ACC is full of some of the best roboticists, engineers and researchers in Australia. It has been very rewarding to work with all these people, seeing how they think and fostering the development of the next batch of robotics thinkers. Even though we are separated across different parts of Australia, we find a way to make it work. ACC researchers are EPIC (Excellent. People-Centric. Innovative. Collaborative.)

If you could give an impromptu 1-hour talk on any topic outside your research, what would it be?

I am an avid maker and creator. I focus on textiles and, being an engineer, my creations tend to be quite mathematical and “constructed” (you should see my kids’ costumes for Book Week!). I love pushing the boundaries of existing techniques, old and new. I could definitely talk about the technology and mathematics of textile creation for hours!

“Exploring Human-Robot Interaction: James Dwyer’s Seminar on Mechamimicry and Prototyping Tools”

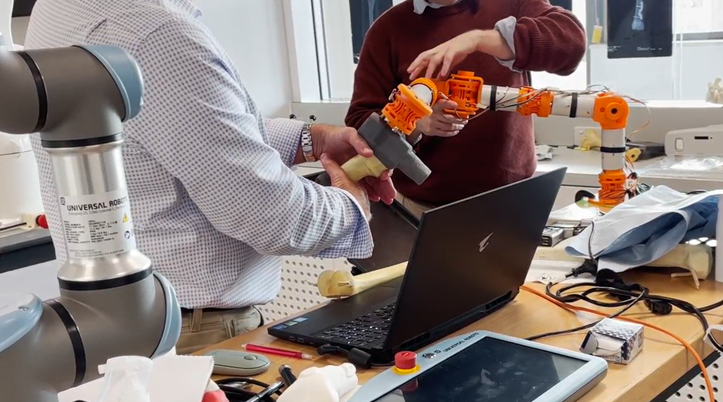
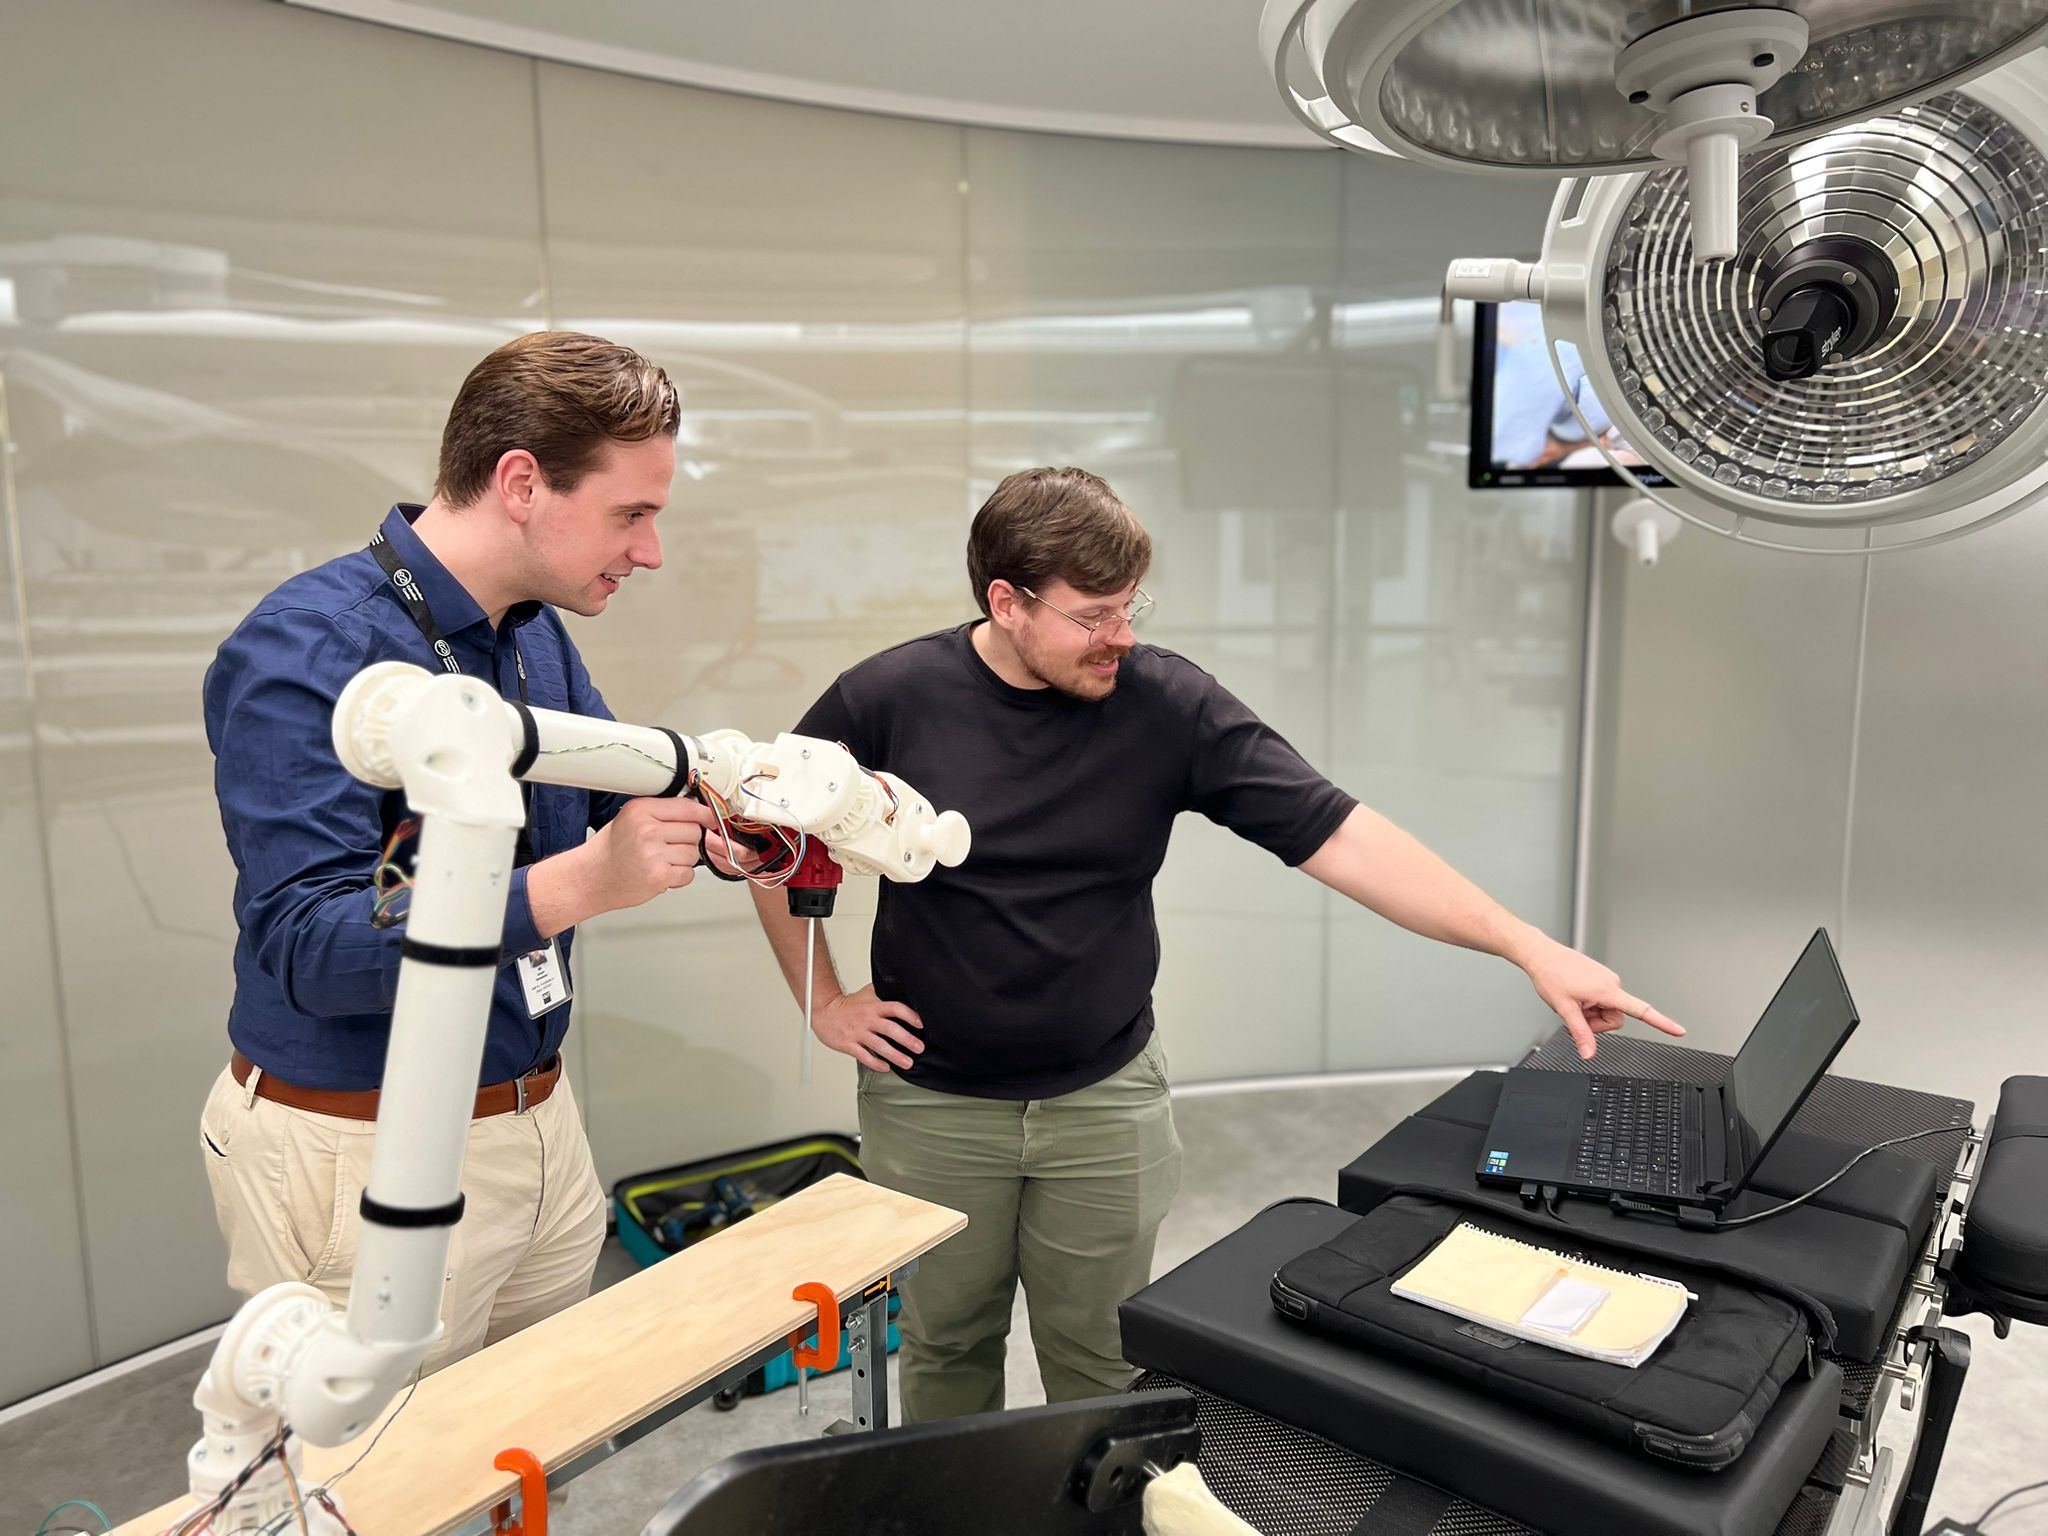
PhD researcher, James Dwyer presented a seminar titled ‘The Art of Mechamimicry: Designing Prototyping Tools for Human-Robot Interaction’ for the QUT Centre for Robotics today.

Supervised by Jared Donovan, Markus Rittenbruch, Dr Valeria Macalupú and Rafael Gomez FDIA, James’s work explores how embodied, low-fidelity prototyping can make abstract HRI concepts tangible and accessible. Through a case study in Robotic Assisted Surgery, he demonstrates how combining physical role-play with virtual simulation helps stakeholders externalise tacit knowledge and co-design better robotic systems.

With a background in Industrial Design and Psychology, James brings a unique perspective to collaborative robotics in both surgical and manufacturing contexts.

Read more about his project, based at QUT (Queensland University of Technology), here: https://lnkd.in/gZXCsyb9

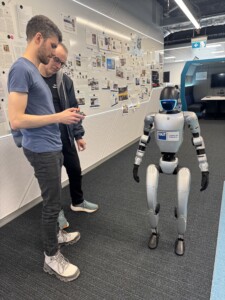
Advancing Humanoid Robotics: Beyond Impressive Demonstrations

Humanoid robots have captured the public’s imagination with their awe-inspiring demonstrations, from backflips and dances to folding laundry. These performances often leave us in awe of their capabilities, showcasing highly sophisticated technology. But at the heart of these demos lies a crucial distinction that is often overlooked: what these robots can do in controlled environments is vastly different from what they can achieve in the real world.

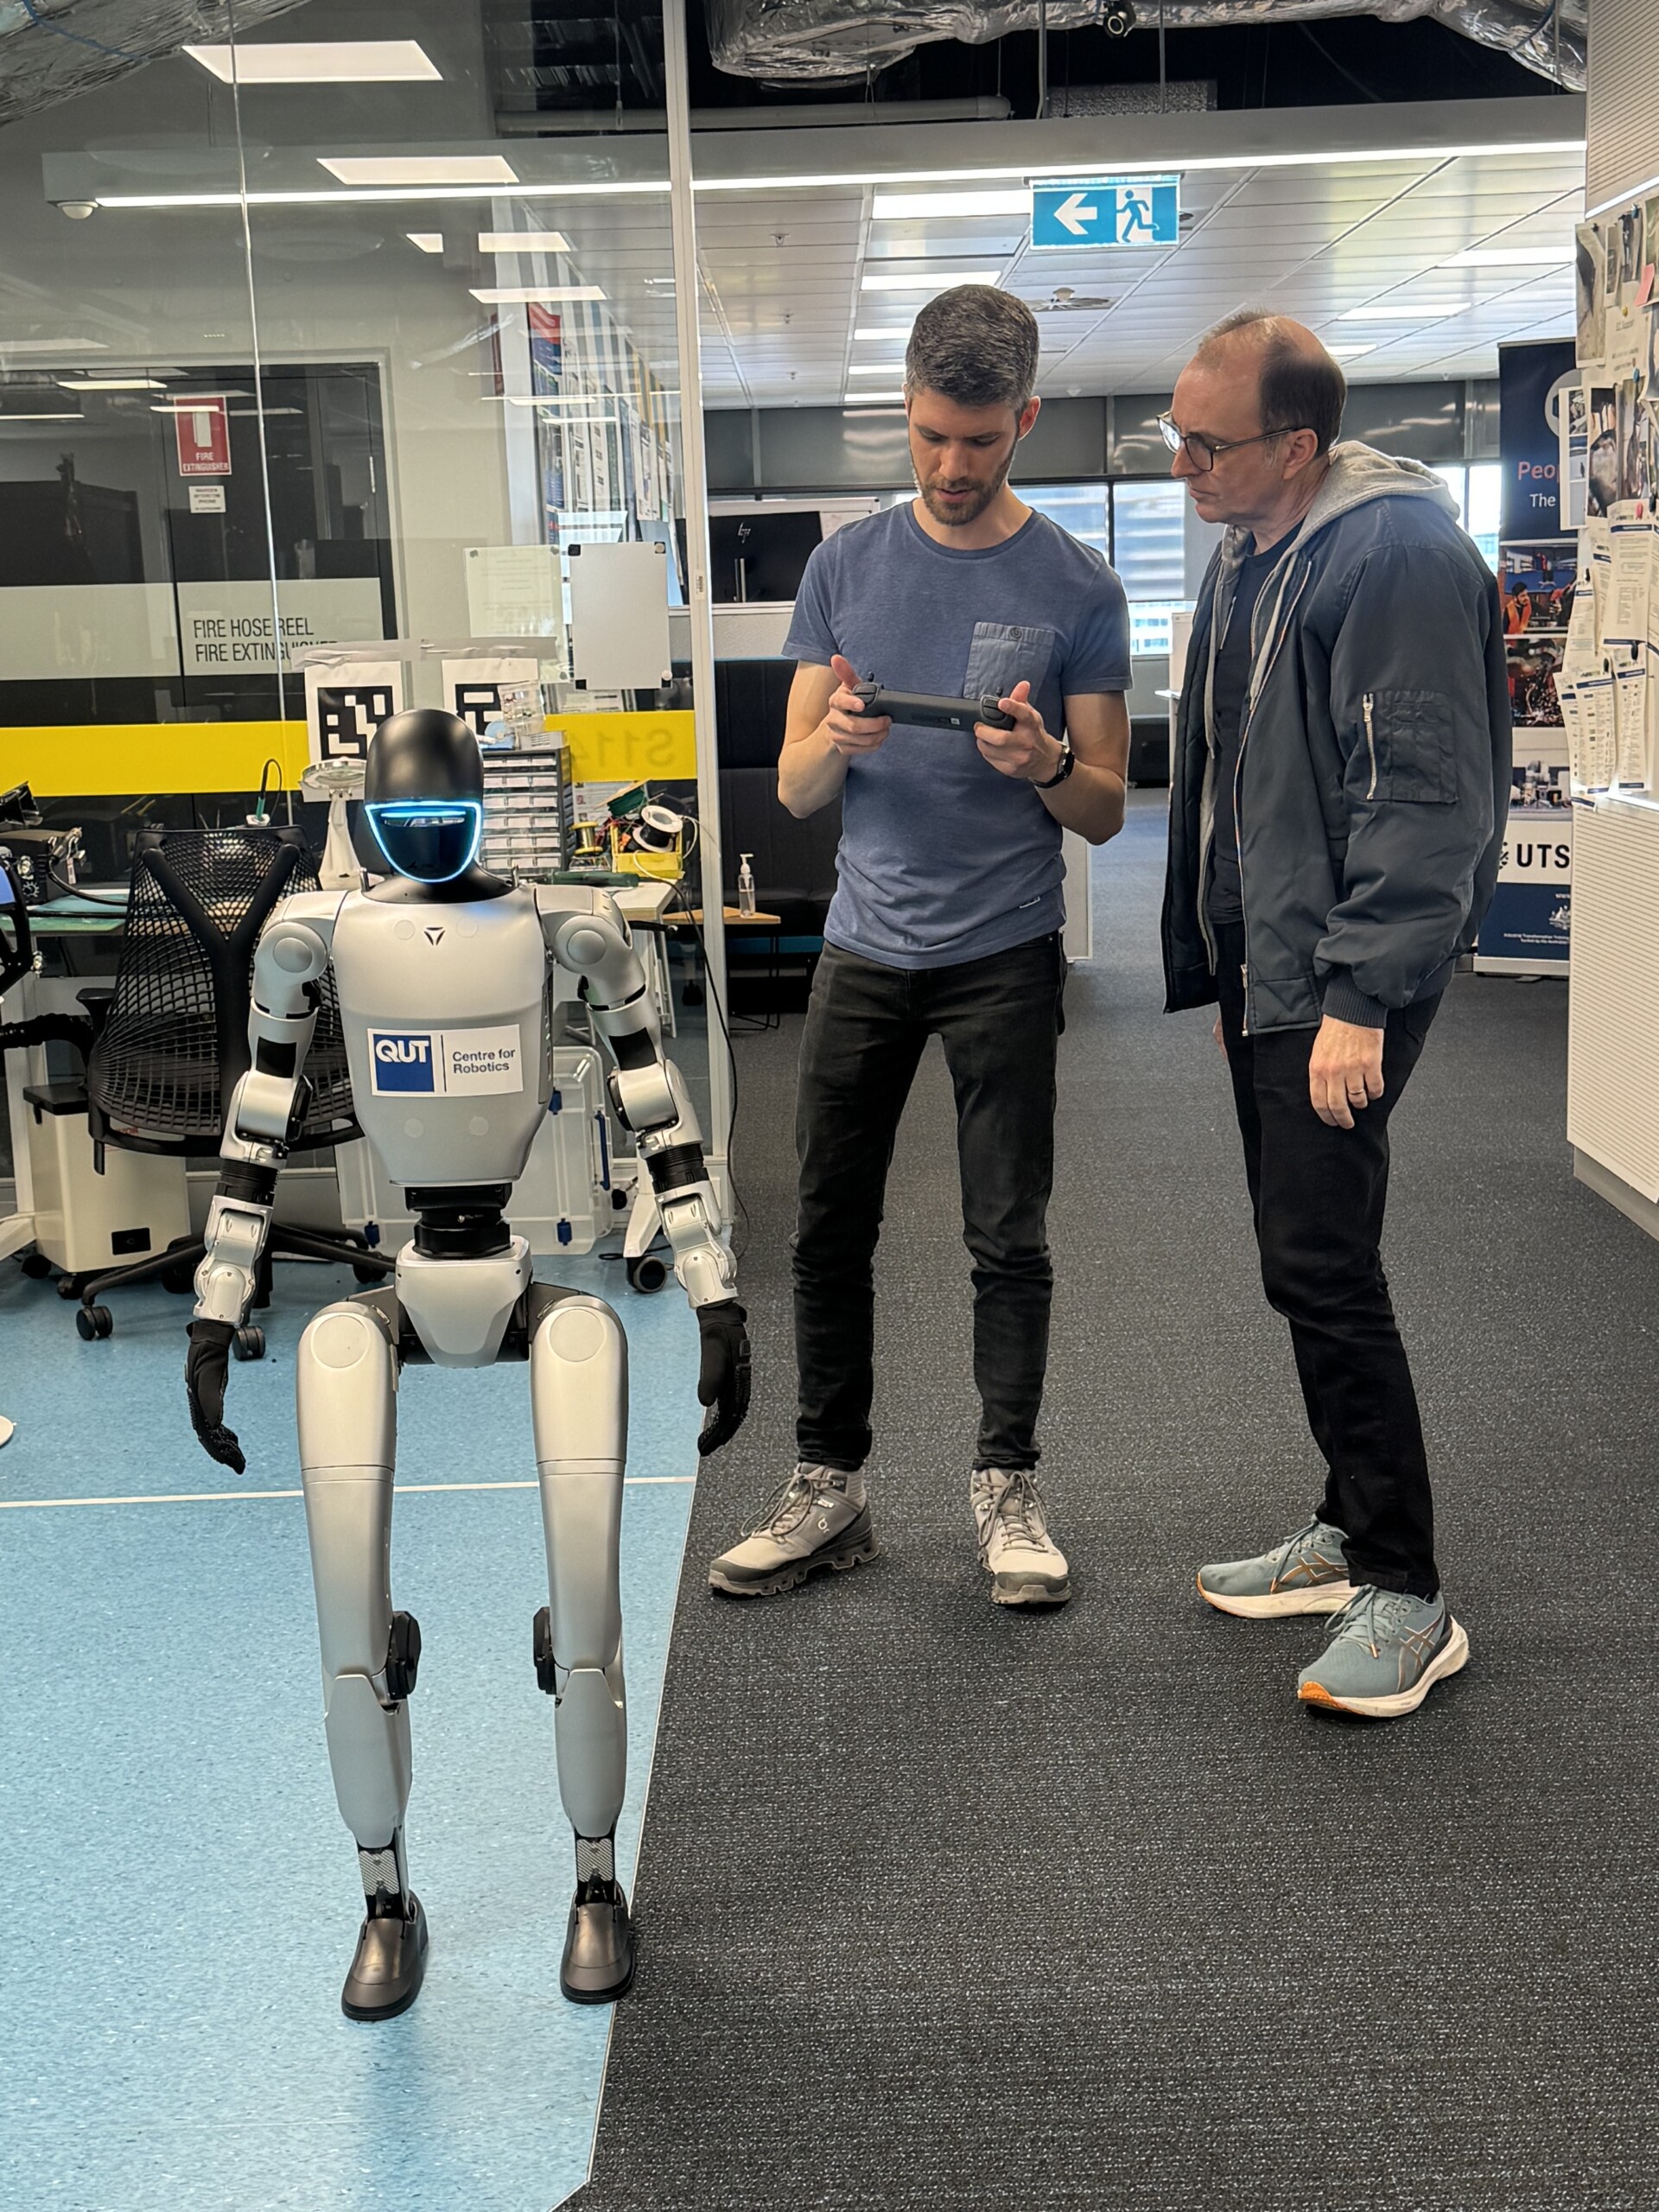
At Swinburne University of Technology (SUT) and Queensland University of Technology (QUT) researchers are shifting the focus from simply impressing audiences to solving the real challenges that come with integrating humanoid robots into everyday environments. Their work aims to bridge the gap between performance-based robotics and true autonomy.

Performance vs. Perception in Humanoid Robots

Most advanced humanoid robot demonstrations rely heavily on predefined motion sequences, scripted environments, and external assistance. The robots perform complex tasks by following a series of carefully orchestrated routines, often created through motion capture, reinforcement learning, or imitation learning in simulated settings. While visually stunning, these robots lack the semantic understanding and real-time reasoning necessary for true independence.

In the real world—whether in homes, hospitals, or factories—robots need much more than impressive pre-programmed actions. They need to:

  • Understand the context of objects and their surroundings

  • Sense the environment in real-time

  • Adapt their control and actions to handle the unpredictable nature of the world

This ability to adapt and truly comprehend is one of the greatest challenges facing robotics today. It’s not enough for robots to simply perform well in rehearsed routines. They must also be able to perceive and respond to dynamic environments.

Collaboration for Real-World Applications

At SUT, the research is aimed at developing humanoid robots that can interact with the world as we do: through contextual awareness and adaptive control. The team is working to address the gap between what robots can perform and how they understand the world around them, an essential step toward making robots more practical for real-world applications.

In this exciting area of research, SUT is eager to collaborate with industry partners to explore collaborative opportunities for research, development, and innovation. The goal is not just to impress but to create robots that can interpret and respond meaningfully to their environments, paving the way for their deployment in real-world scenarios.

As the Australian Cobotics Centre continues to explore the diverse capabilities of collaborative robots (cobots), we look forward to seeing how these advancements in humanoid robotics will contribute to the broader field. Whether in healthcare, manufacturing, or beyond, the future of humanoid robots is about intelligence, not just impressive demonstrations.

High Achiever HDR Student Award Recognition

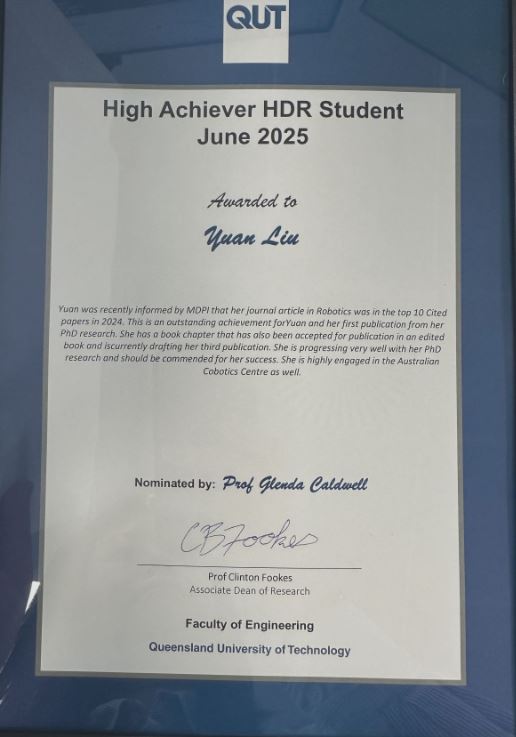
In June 2025, Yuan Liu was honoured to receive the High Achiever HDR Student Award from the QUT Faculty of Engineering. This recognition is a testament to the dedication and hard work put into her research journey. She is deeply grateful to her principal supervisor, Professor Glenda Caldwell, for the nomination, and to Professor Markus Rittenbruch, Associate Professor Müge Belek Fialho Teixeira, Dr. Alan Burden, and Dr. Matthias Guertler for their ongoing support and guidance. This prestigious award serves as motivation for Yuan to continue advancing her research and pushing the boundaries of her work.

ARTICLE: Automating Asset Management Tasks in Factory Settings

As the Asset Management Council of Australia emphasizes, effective asset management provides organizations with insights across four critical domains: physical, information, financial, and intellectual assets. When implemented successfully, it enhances decision-making, strengthens operational resilience, and delivers long-term value. This capability serves as a key differentiator between agile, modern factories and slower, fragmented legacy operations.

The next frontier of asset management explores the shift from human-dependent monitoring to autonomous systems—where assets effectively manage themselves.

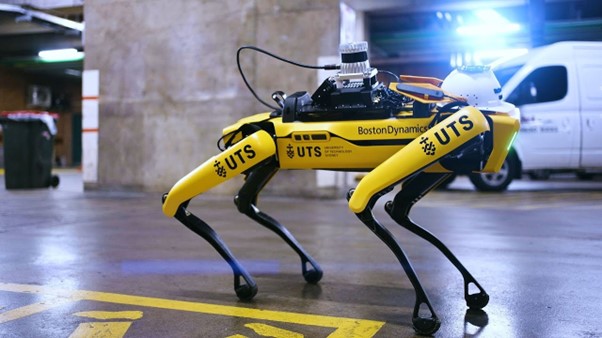
Under the Australian Cobotics Centre’s (ACC) Quality Assurance and Compliance program, researchers at the UTS:Robotics Institute are advancing this concept through the deployment of Boston Dynamics’ robotic platform, Spot. In this implementation, Spot autonomously navigates industrial environments, constructs a digital map, captures detailed imagery of equipment such as pipes, coils, and panels, and performs inspection tasks without human supervision.

Collaborative robots, or cobots, play a critical role in this evolving landscape. Designed to complement rather than replace human workers, cobots enhance manufacturing resilience by integrating human judgment with machine-level consistency and precision. Studies by [1] and [2] highlight the synergy of cobots and human teams in improving factory adaptability.

In this approach, robots such as Spot undertake detailed inspection routines, while humans execute follow-up tasks—tightening components, initiating repairs, or notifying human operators through shared digital interfaces. A supporting fleet management system, as outlined by [3], enables real-time tracking of cobot performance, usage, and maintenance status, effectively treating each cobot as a digital asset within the broader ecosystem.

In field trials, Spot demonstrated 90 minutes of continuous operation without a battery swap, covering 7.5 kilometers of factory floor—equivalent to 75,000 m². This capacity enables a single robot to replace multiple manual inspection rounds per shift in a typical Australian SME manufacturing facility.

A key innovation in the system is an integrated asset-management dashboard that connects directly to the SPOT’s API. By aggregating live telemetry, annotated inspection imagery, and equipment metadata, the dashboard eliminates the need for manual data entry. During initial deployments, Spot completed multi-kilometre inspection loops and uploaded over 6,000 annotated images per shift, delivering a comprehensive, timestamped view of equipment health. The dashboard’s real-time capabilities position it as a dynamic decision-support tool, advancing the transition from reactive maintenance to proactive, autonomous operations.

This trial represents a foundational step toward scaling autonomous survey robotics across industry. The integration of AI-driven perception, robotic mobility, and collaborative tasking is redefining the asset management paradigm.

The convergence of autonomous robotics, AI-powered vision systems, and collaborative machines signals a fundamental transformation in industrial asset management. Tasks once characterized by manual oversight are becoming intelligent, continuous processes. Initiatives such as those under the Australian Cobotics Centre offer a forward-looking model where factory systems are capable of sensing, interpreting, and responding with minimal human input—enabling safer, smarter, and more resilient operations across the manufacturing sector.

Citation: https://www.nbnco.com.au/blog/the-nbn-project/the-power-of-robotics-to-lift-digital-capability

Text – Asset Dashboard

[1]           J. Pizoń, M. Cioch, Ł. Kański, and E. Sánchez García, “Cobots Implementation in the Era of Industry 5.0 Using Modern Business and Management Solutions,” Adv. Sci. Technol. Res. J., vol. 16, no. 6, pp. 166–178, Dec. 2022, doi: 10.12913/22998624/156222.

[2]           A. R. Sadik and B. Urban, “An Ontology-Based Approach to Enable Knowledge Representation and Reasoning in Worker–Cobot Agile Manufacturing,” Future Internet, vol. 9, no. 4, Art. no. 4, Dec. 2017, doi: 10.3390/fi9040090.

[3]           B. I. Ismail, M. F. Khalid, R. Kandan, H. Ahmad, M. N. Mohd Mydin, and O. Hong Hoe, “Cobot Fleet Management System Using Cloud and Edge Computing,” in 2020 IEEE 7th International Conference on Engineering Technologies and Applied Sciences (ICETAS), Dec. 2020, pp. 1–5. doi: 10.1109/ICETAS51660.2020.9484266.