Member Login

Humanoid Robotics in the Spotlight: Australian Cobotics Centre Researchers Share Expertise with National Audiences

Humanoid Robotics in the Spotlight: Australian Cobotics Centre Researchers Share Expertise with National Audiences

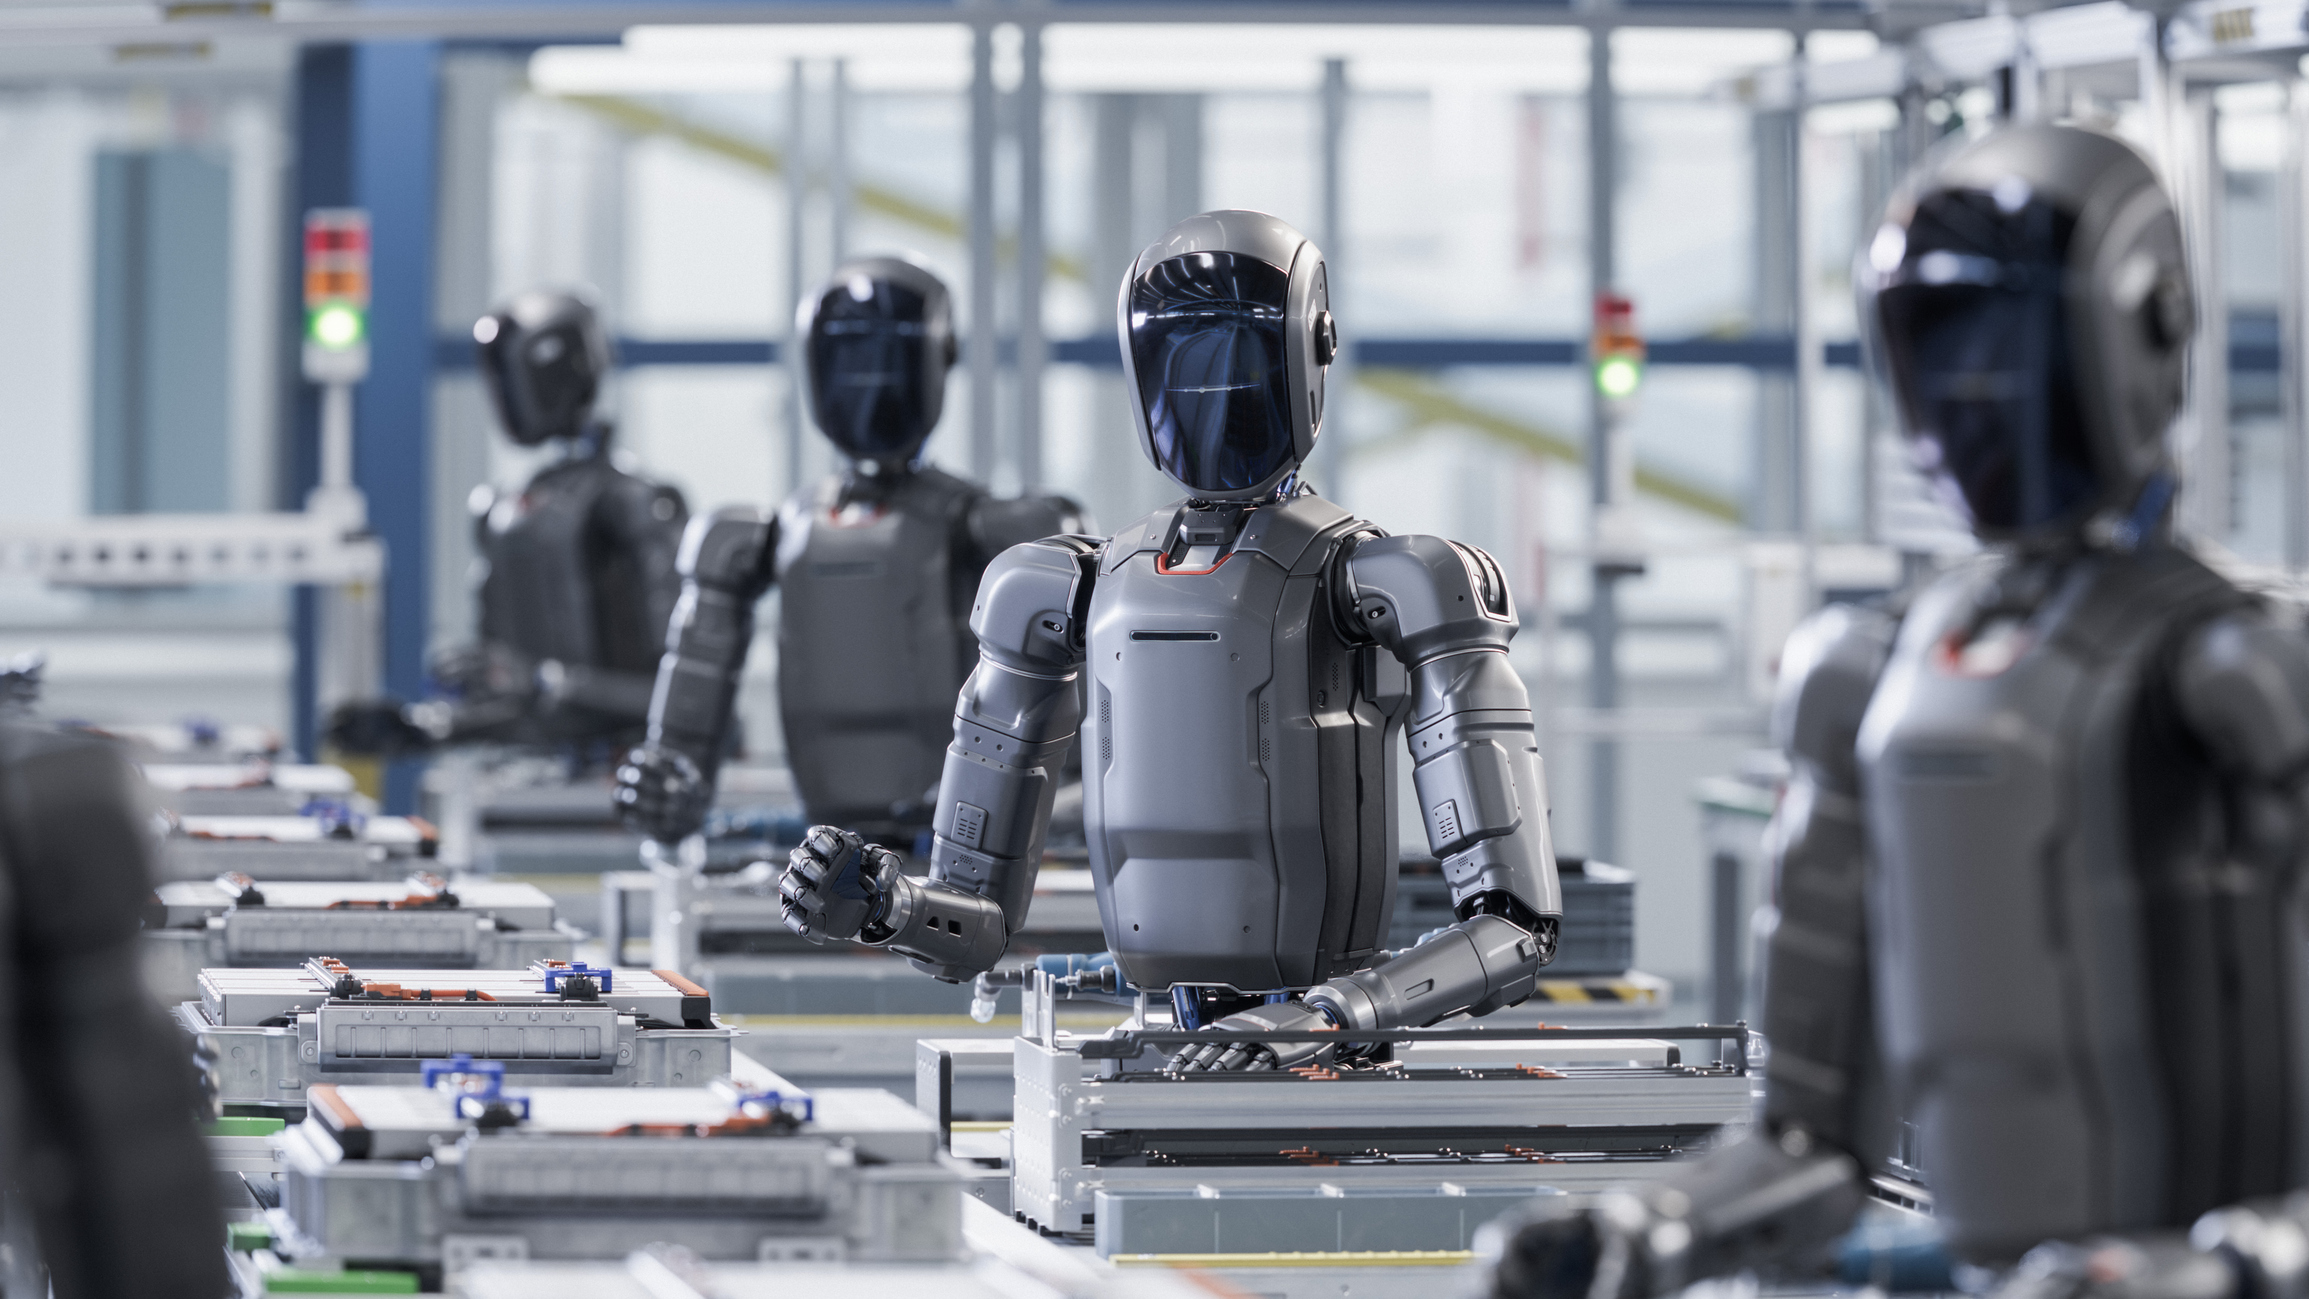
Humanoid robotics has captured global attention over the past year, driven by rapid advances in artificial intelligence, increasingly capable robotic platforms, and high-profile events such as the World Humanoid Robot Games. As public interest continues to grow, researchers from the Australian Cobotics Centre and the QUT Centre for Robotics have been helping audiences understand both the opportunities and challenges presented by these emerging technologies.

Throughout recent months, Professor Jonathan Roberts, Director of the Australian Cobotics Centre and QUT Centre for Robotics researcher, has appeared across television, radio and online media to discuss the current state of humanoid robotics, the impact of embodied AI, and the potential future role of humanoids in workplaces and everyday life.

Bringing Humanoid Robotics to a Wider Audience

Media appearances included interviews on ABC Radio, ABC Weekend Breakfast, and coverage connected to the World Humanoid Robot Games, helping explain what recent developments mean for industry and society.

A particular highlight was a feature on the Today Show, where Professor Roberts appeared alongside researcher Lauren Sherlock and two of QUT’s humanoid robots. Supported behind the scenes by Zongyuan Zhang as “Robot Wrangler”, the segment demonstrated humanoid robotics in action and provided viewers with a glimpse of how quickly the technology is evolving.

The team also featured on ABC Behind the News (BTN), introducing younger audiences to robotics and AI concepts and helping inspire future generations of researchers, engineers and innovators.

Through these appearances, Australian Cobotics Centre researchers have played an important role in moving the discussion beyond science fiction and helping the public understand the practical realities of humanoid robotics, including current capabilities, limitations and future applications.

From Research Labs to Real-World Conversations

Humanoid robots are increasingly capable of performing tasks that require mobility, perception and interaction with people. While significant technical challenges remain, advances in sensing, machine learning, embodied AI and human-robot interaction are accelerating development across the sector.

Researchers from the Australian Cobotics Centre continue to investigate many of these challenges, exploring how robots can safely and effectively work alongside people in manufacturing, healthcare and other human-centred environments.

The growing public interest generated by events such as the World Humanoid Robot Games has created valuable opportunities for researchers to discuss broader questions relating to trust, safety, workforce impacts, ethics and the role of robotics in society.

Humanoids at Swinburne

The excitement around humanoid robotics extended beyond Queensland, with researchers from Swinburne University of Technology also showcasing their work through national media appearances.

Swinburne’s humanoid robots SUT 3PO and Roci recently featured on Channel 7’s Sunrise program, where they interacted with weather presenter Sam Mac and students from John Monash Science School. The segment also incorporated Swinburne’s motion-capture technology, allowing students to experience live interaction within a virtual environment while exploring the possibilities of human-robot collaboration.

These demonstrations highlighted the combination of robotics, artificial intelligence, immersive technologies and education that is helping shape the next generation of intelligent systems.

Exploring the Humanoid Olympics

The conversation around humanoid robotics was also explored through a feature article examining the significance of the World Humanoid Robot Games and what these events reveal about the future direction of robotics research.

The article considered how competitions provide a valuable benchmark for evaluating humanoid capabilities while also stimulating discussion around the future deployment of embodied AI systems in factories, hospitals, homes and public spaces.

Watch and Listen

Catch up on some of the recent media coverage:

  • ABC Behind the News (BTN)
  • Today Show appearance featuring Professor Jonathan Roberts, Lauren Sherlock and QUT’s humanoid robots
  • ABC Radio interviews
  • ABC Weekend Breakfast coverage
  • Channel 7 Sunrise featuring Swinburne humanoids SUT 3PO and Roci
  • The Conversation article on the World Humanoid Robot Games and the rise of humanoid robotics

As humanoid robotics continues to evolve, Australian Cobotics Centre researchers remain committed to providing evidence-based insights that help industry, government and the wider community understand the implications of these rapidly advancing technologies. From television studios to research laboratories, these conversations are helping shape a more informed discussion about the future of robots in our society.
MegaTrans 2026: Where Robotics Meets the Future of Logistics

MegaTrans 2026: Where Robotics Meets the Future of Logistics

As Australia’s freight, warehousing and logistics sectors face growing pressure to improve productivity, sustainability and resilience, automation and robotics are becoming an increasingly important part of the conversation. This year’s MegaTrans 2026 brought together industry leaders, technology providers, researchers and decision-makers to explore what the future of supply chains could look like and the role emerging technologies will play in shaping it.

Held at the Melbourne Convention and Exhibition Centre on 16-17 September, MegaTrans is Australia’s largest integrated logistics and supply chain conference and exhibition. The event showcases innovations across freight, warehousing, transport, infrastructure and technology, creating a unique platform for industry to explore solutions to current and future operational challenges.

Robotics Takes Centre Stage

A key theme throughout MegaTrans 2026 was the growing adoption of automation across logistics and warehousing. Organisations are increasingly seeking technologies that can improve efficiency, address workforce shortages and create safer workplaces while maintaining flexibility in rapidly changing supply chains.

The event highlighted how robotics has moved beyond being a future aspiration and is now becoming a practical tool for solving real operational challenges. Autonomous mobile robots, collaborative robots, intelligent sensing systems and warehouse automation technologies were all featured as examples of how organisations are transforming day-to-day operations.

Australian Cobotics Centre at MegaTrans

The Australian Cobotics Centre was represented at the event through the Swinburne University of Technology stand, where researchers showcased emerging robotics capabilities and their potential applications across logistics, manufacturing and industry. Visitors had the opportunity to see a range of robotic technologies in action, including humanoid robots, collaborative robots and autonomous systems designed to work alongside people.

Live demonstrations provided a valuable opportunity for industry representatives to engage directly with researchers, ask questions and explore how robotics technologies might be applied within their own organisations. These conversations reflected growing interest in practical deployment pathways and the broader challenges associated with integrating robotics into existing operations.

Human-Robot Collaboration in Logistics

While discussions around automation often focus on technology, MegaTrans also highlighted the importance of people. The future of logistics is unlikely to be fully automated; instead, it will increasingly depend on effective collaboration between humans and intelligent systems.

This aligns closely with the Australian Cobotics Centre’s research focus. Across projects in manufacturing, logistics and service industries, Centre researchers are investigating how robots can support workers rather than replace them. Human-centred design, trust, safety, usability and workforce capability remain critical considerations for successful implementation. These factors are particularly important in logistics environments where flexibility, decision-making and real-time problem solving are essential.

Looking Ahead

With freight volumes expected to continue growing over the coming decades, industry must find new ways to improve efficiency while maintaining sustainability and workforce wellbeing. MegaTrans demonstrated that robotics and automation will be central to this transition, not as standalone technologies but as part of broader systems that combine people, processes and intelligent tools.

For the Australian Cobotics Centre, events such as MegaTrans provide an important opportunity to connect with industry, understand emerging challenges and ensure research continues to address real-world needs. From warehouses and distribution centres to manufacturing facilities and transport networks, the future of work will increasingly involve collaboration between people and robots.

MegaTrans 2026 offered a glimpse of that future and reinforced the important role Australian research and innovation will play in helping shape it.

ARTICLE: Collaborative Robotics in Japan 


By Dr Sheila Sutjipto

Last year, Professor Teresa Vidal-Calleja and I travelled to Japan primarily for a focused research collaboration at the Tokyo University of Science (TUS). While our joint work at TUS constituted the core of the trip, Teresa also took the opportunity to visit and deliver talks at several other leading research institutions across the country. This opportunity provided a comprehensive look at the broader Japanese robotics landscape, spanning space exploration, disaster recovery, social robotics, and human-robot interaction. 

A Landscape of Service and Innovation in Robotics Research 

A recurring theme across the institutions Teresa visited was the development of service and assistive robots designed to support human society. At Tohoku University, the Smart Robotics Design Lab is developing human-assist robots for caregiving and healthcare to support an aging population. Similarly, the Nara Institute of Science and Technology (NAIST) focuses on integrating machine learning and artificial to advance human-robot collaboration in real world applications. 

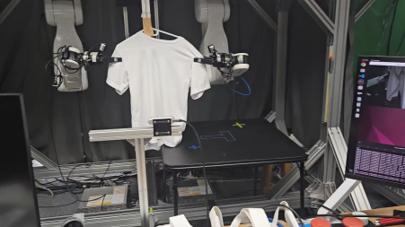
Figure: A robotic system designed for service robotics by the Smart Robot Design Lab in Tohoku University. It is trained to manipulate a deformable object like a t-shirt addressing housework tasks.
Figure: A humanoid learning to navigate environments with obstacles at the Neuro-Robotics lab in Tohoku University 
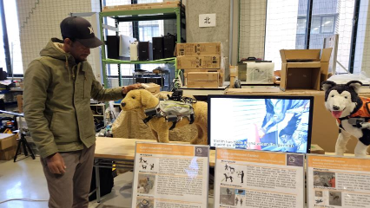
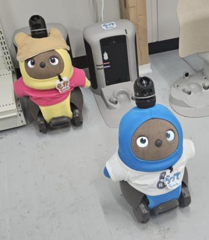
Figure: Companion robots used as a research platform for Human-Robot Interaction by the Smart Robot Design Lab at Tohoku University 
Figure: A robotic system designed by researchers from the Robot Learning lab at NAIST. It is designed to perform automated grinding of workpieces. 


The applications she encountered were highly diverse. Her visits included the Institute of Science – Tokyo’s Robotics and AI Laboratory, which focuses on robot audition and environment understanding, as well as Hokkaido University, where they address research in automated infrastructure inspection and autonomous driving for snowy environments.

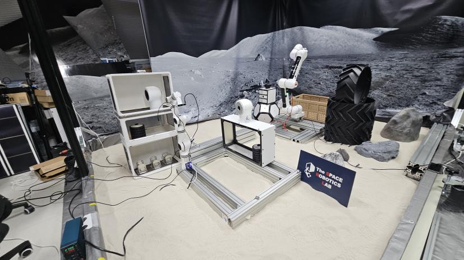
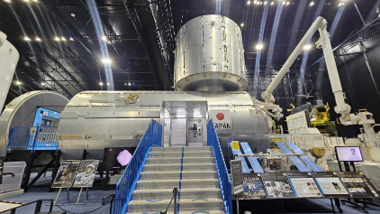
Additionally at Tohoku University, she observed autonomous systems and sensing units designed for extreme conditions at the Tough Robotics Lab and extraterrestrial exploration at the Space Robotics Lab. Teresa also attended The International Conference on Space Robotics (ISpaRo 2025) whilst in in Sendai. This event brought together aerospace experts, academia, and industry professionals to discuss innovations in space exploration. 

Figure: Sensing units designed for dogs working in search and rescue 
Figure: A test environment at the Space Robotics Laboratory at Tohoku University
Figure: Full scale model of the JAXA Kibo ISS Module showcased at ISpaRo 


These visits and talks provided valuable insights into the scope and societal focus of Japan’s robotics ecosystem, highlighting the diverse platforms currently being developed by researchers across Japan. 

 The TUS Collaboration: Merging Perception with Human-Centric RL 

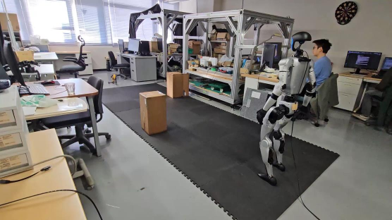
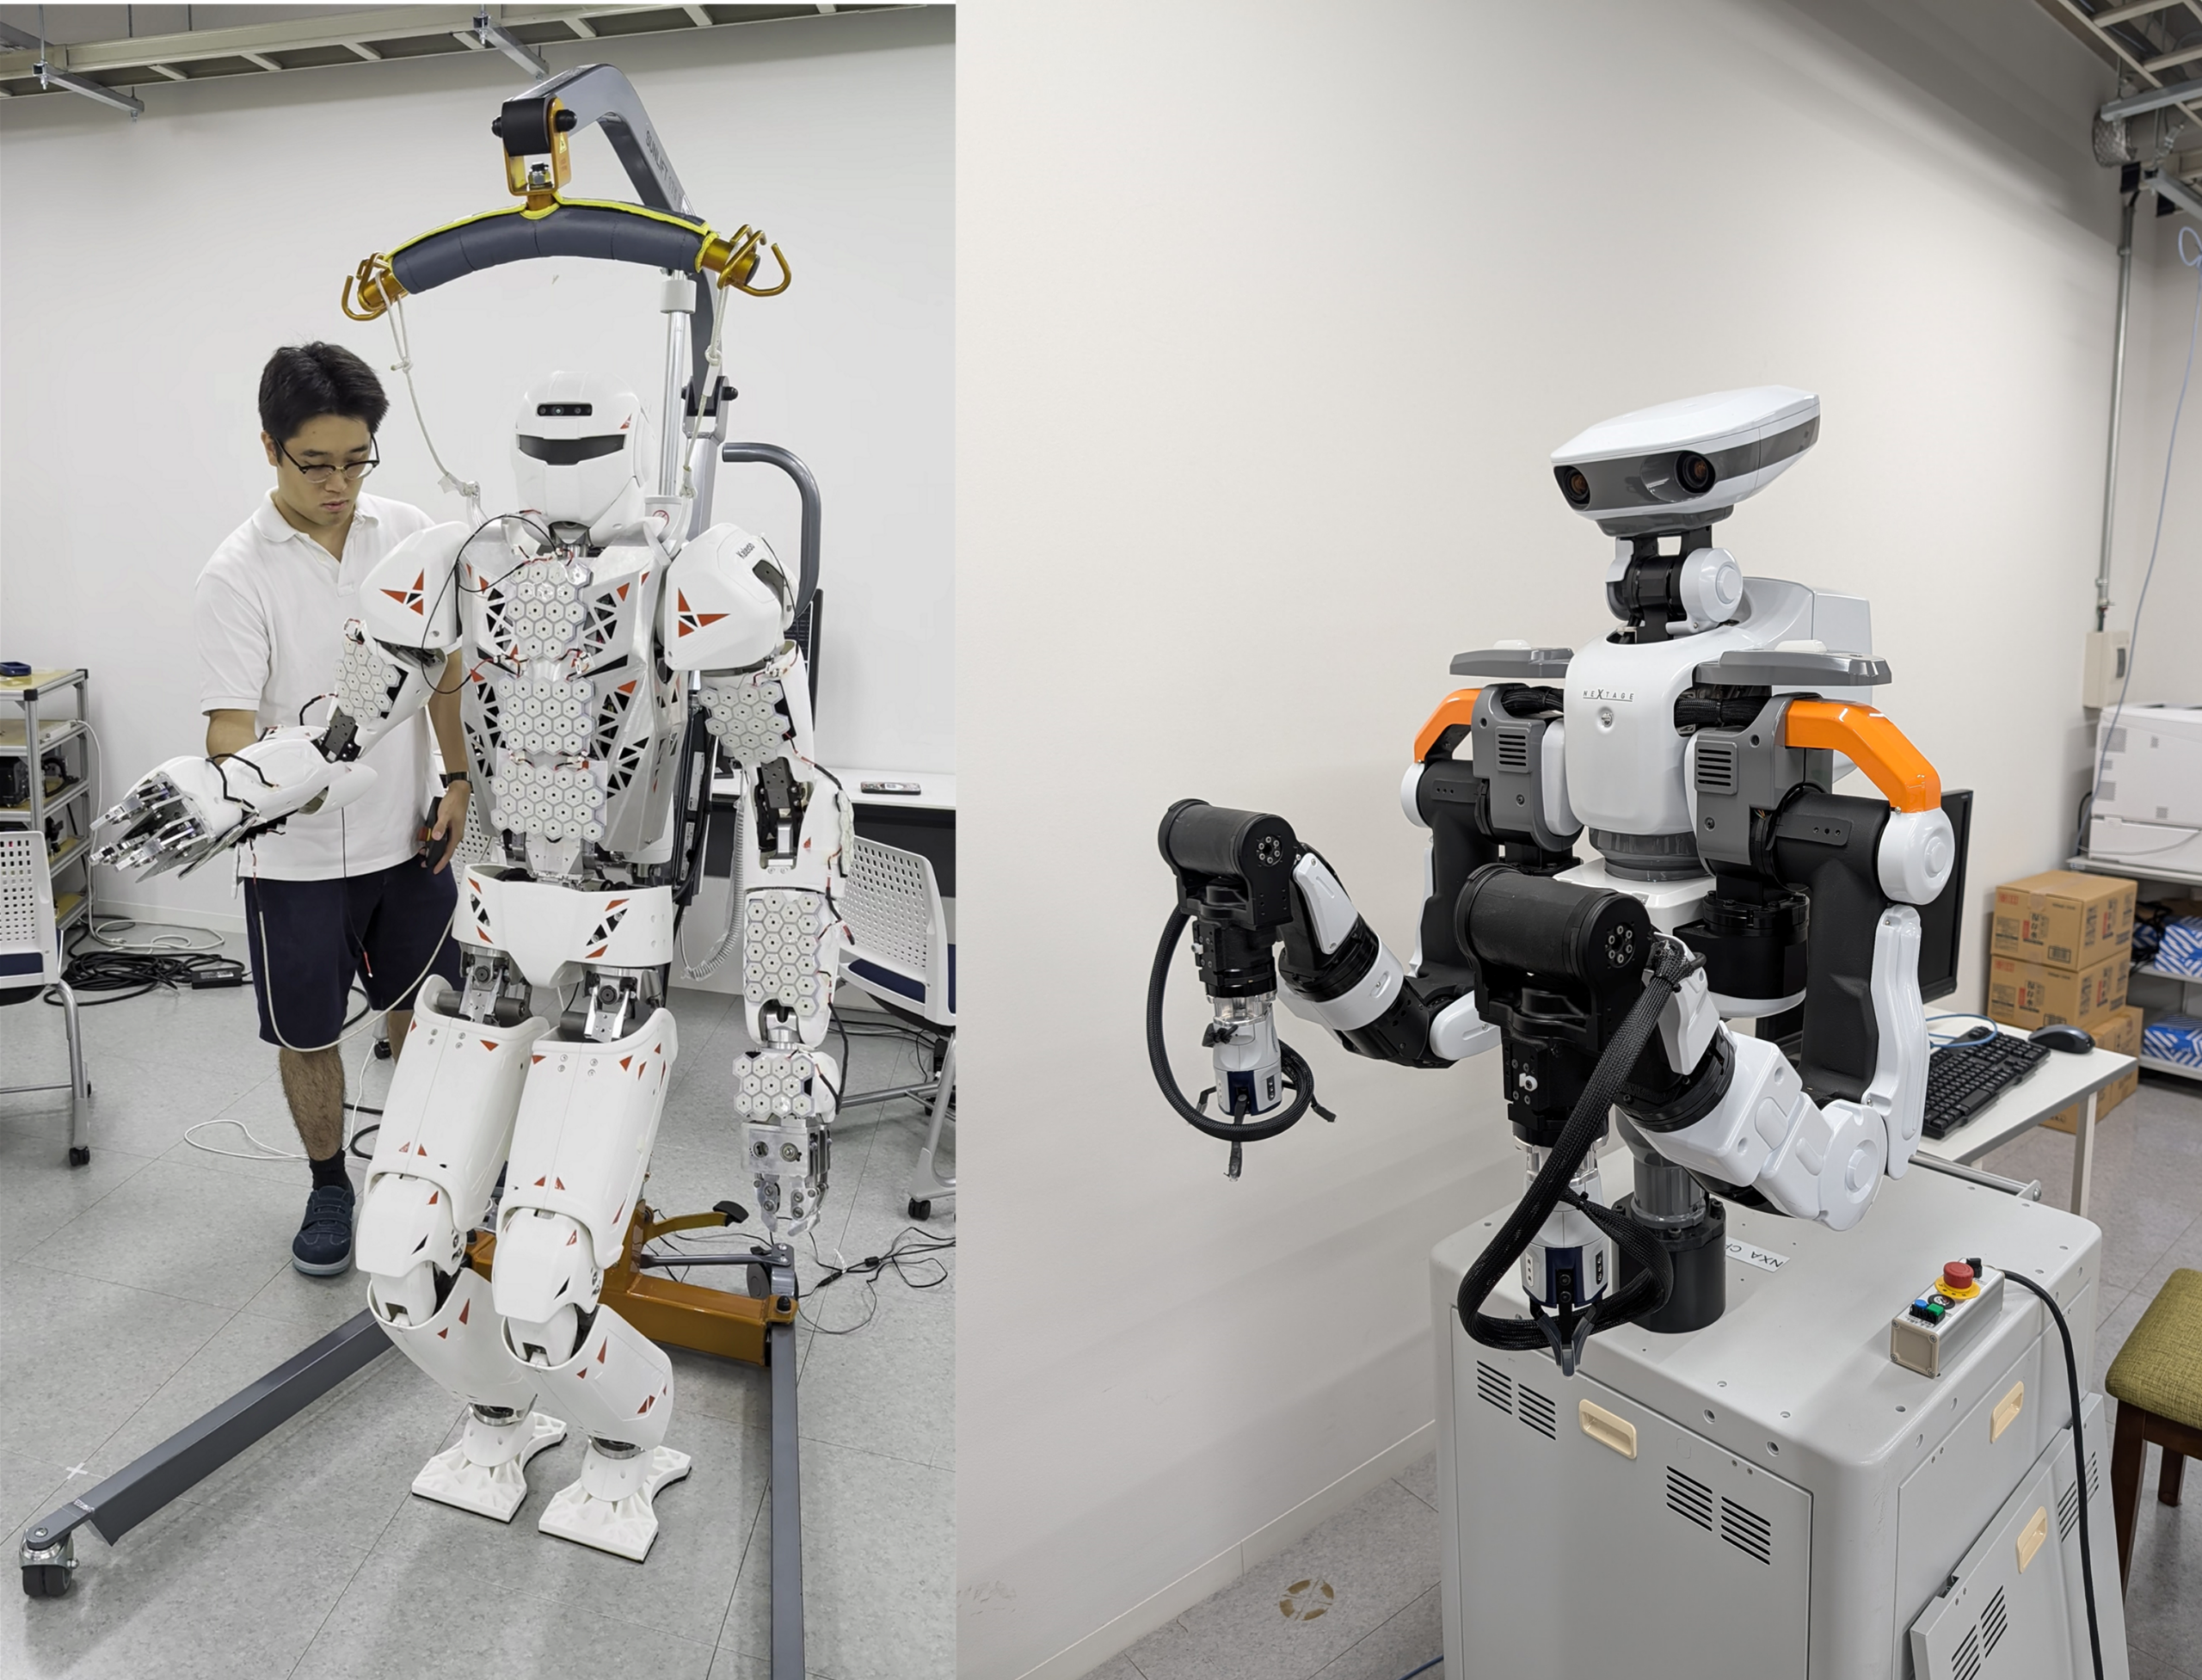
The primary research component of this trip was our collaboration with the Interactive Robotics Lab (Yoshida Lab) at TUS. TUS aims to make robots more intelligent by understanding human behaviour, utilising digital twins to simulate environments and humanoid robots to validate theories of natural motion. 

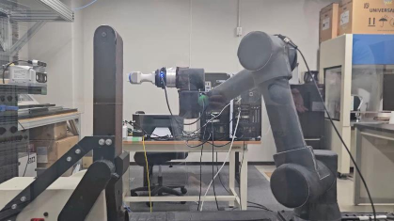
Figure: Two robotic platforms used for research at the Interactive Robotics Lab at TUS. Left: The Kaleido humanoid attached with tactile skin sensors. Right: Dual arm industrial robot


Our research streams are complementary where TUS has directed their research toward human-centric robotics, human-understanding and machine learning, and the team at the Australian Cobotics Centre focuses on cobots, perception, and how to intelligently construct and utilise representations of the environment. Our shared goal was to integrate our proposed research directly into TUS’s frameworks to create smarter, more efficient robot behaviours. 

During our time in the lab, we focused on three interconnected challenges in cobot manipulation: 

First, we looked at spatial awareness. We wanted to explore how continuous geometric information, specifically EDFs could be integrated directly into learning frameworks to give robots a better understanding of their environment and bridge the gap between simulation and reality. 

Second, we addressed the complexity of redundant manipulators. When a robot has an infinite number of ways to move its arm to reach a target, calculating the most efficient, collision-free path is computationally expensive. We wanted to explore a better way to map these possibilities and find a suitable trajectory. 

Finally, we challenged the traditional approach to clutter. Standard perception systems treat obstacles as strict “no-go” zones. However, humans use the natural redundancy of their arms to gently push minor obstacles aside while reaching for a goal. We aimed to apply this physical intuition to cobots, allowing them to safely interact with their environment rather than simply avoiding it. 

Outcomes 

This collaboration established an ongoing research pipeline between our institutions, resulting in three joint publications that advance cobot planning and motion: 

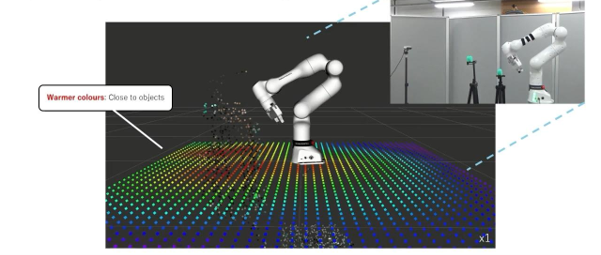
Bridging the Sim-to-Real Gap (International Conference on Intelligent Robots and Systems, IROS): We developed an RL framework that uses Euclidean Distance Fields (EDF) directly as the robot’s observation space. This gives the agent continuous geometric information about its environment, allowing for “zero-shot” transfer from simulation to a physical 7-DoF redundant manipulator. The real robot successfully generalised to unseen environments and avoided dynamic obstacles in real-time, despite being trained only on static objects. 

Figure: A robot with surrounding obstacles (green balls). Using the camera on the left of the setup, a visualisation of the environment is generated where warmer colours indicate proximity to an obstacle 


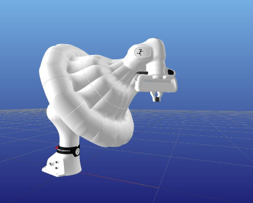
Leveraging redundancy (Robotics: Science and Systems, RSS): We explored methods for leveraging manipulator redundancy to execute complex paths. Using efficient null-space sampling, we mapped the configuration space manifold for specific trajectories in the task space. This enabled us to create a distance field in configuration space, providing the robot with a highly efficient way to calculate collision-free trajectories. 

Figure: This image shows the infinite number of arm configurations the robot can be in whilst maintaining the same tool location and orientation.  

Whole-Arm Safe Push and Place: In a forthcoming journal publication, we propose an alternative to strict obstacle avoidance. We designed a system that allows a cobot to hold an object in its end-effector while using its intermediate arm links to push obstacles out of the way. By using environmental information from the EDF with tactile feedback and enabling the robot to dynamically adjust its task speed during contacts, the robot can safely clear its own path, mimicking human behaviour. 

Figure: A robot using its elbow and forearm to push a box out of its way so it can complete its designated task. 


Looking Ahead 

These outcomes highlight the value of international collaboration. By combining TUS’s expertise in RL and human-centric robotics with our focus on perception and cobots, we addressed complex challenges that would be difficult to solve independently. The insights and frameworks developed during this trip continue to inform our ongoing research at the Australian Cobotics Centre. 

France24 Article – AI robot cleaners leave the lab for China’s living rooms

Great to see Dr Valeria Macalupú featured in this recent FRANCE 24 article on AI robot cleaners moving into everyday homes.

As a postdoctoral researcher in our Human-Robot Interaction program, Valeria brings deep expertise in social and care robotics, helping us understand not just what robots can do, but how people experience and trust them in real-world settings.

Her inclusion in this article highlights the growing importance of human-centred design as robots move beyond the lab and into daily life.

READ THE ARTICLE

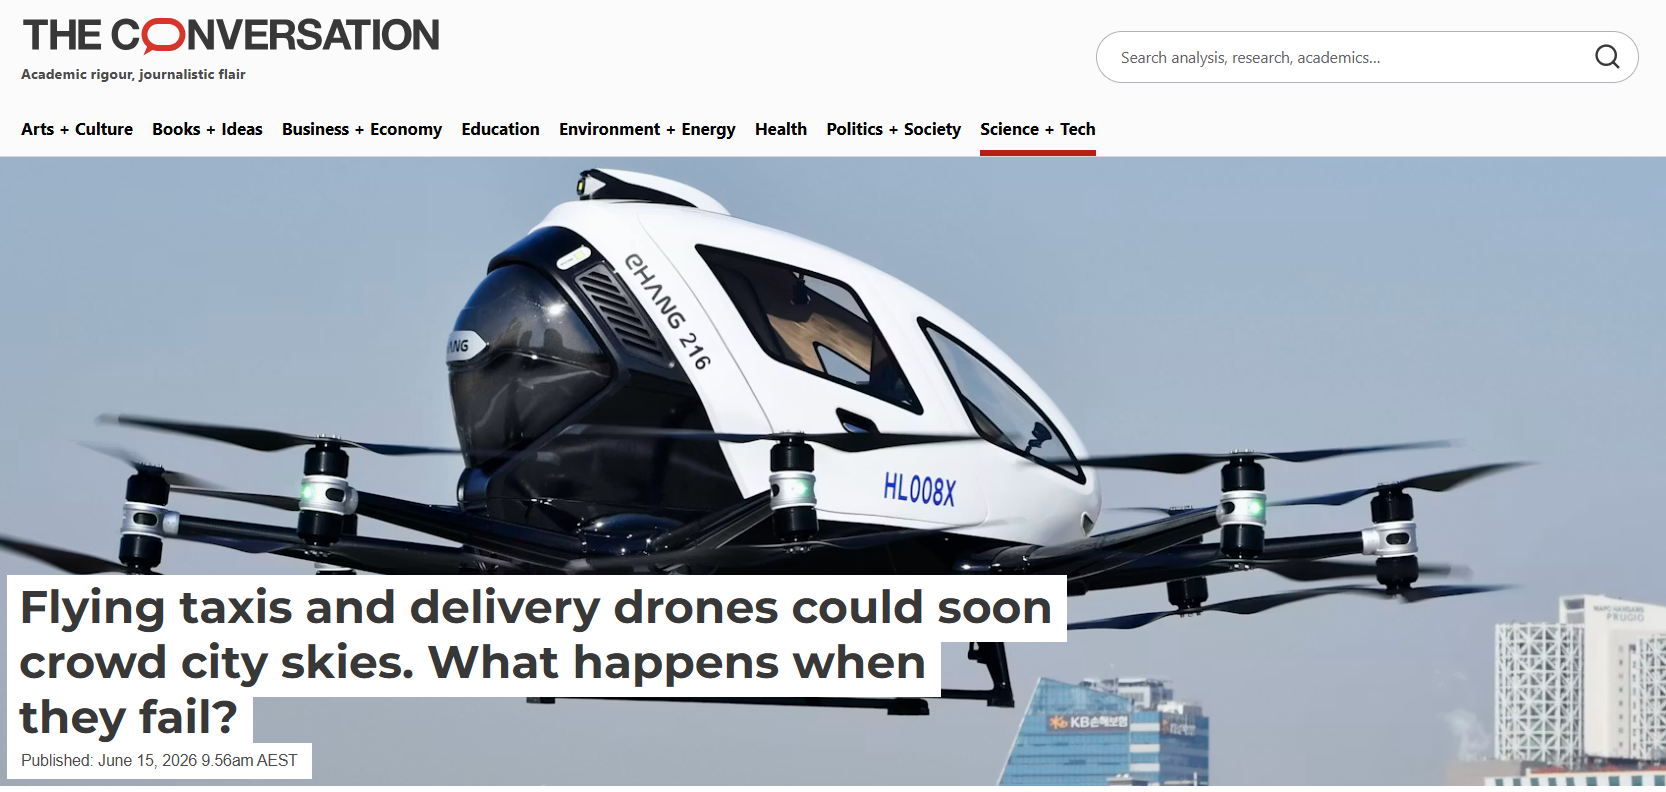
The Conversation article: Flying taxis and delivery drones could soon crowd city skies. What happens when they fail?

Centre Director Professor Jon Roberts recently co-authored an article in The Conversation with QUT Centre for Robotics Chief Investigator Professor Luis Mejias, examining the challenges that can lead to drone failures—prompted by a recent incident at Sydney’s Vivid Festival.

The article explores the technical, environmental and operational factors that can affect drone performance in complex, real-world settings, particularly during large-scale public events. It also highlights the importance of robust system design, risk management, and regulatory oversight as drone use continues to expand.

This contribution reflects the Centre’s expertise in autonomous systems and its role in informing public understanding of emerging robotics technologies.

Read the article: Flying taxis and delivery drones could soon crowd city skies. What happens when they fail?

ICRA 2026 in review

ICRA 2026: Showcasing Impact on the Global Robotics Stage

Researchers from the Australian Cobotics Centre and its partner institutions made a strong contribution to the IEEE International Conference on Robotics and Automation (ICRA) 2026, held in Vienna—one of the world’s leading forums for robotics research.

Across the week, Centre researchers presented work spanning healthcare robotics, advanced manufacturing, and real-time perception, highlighting both technical innovation and real-world application.

Advancing robotic healthcare

A key contribution came from Mariadas Capsran Roshan (Swinburne University of Technology), who presented the paper “Finding an Initial Probe Pose in Teleoperated Robotic Echocardiography via 2D LiDAR-Based 3D Reconstruction”, co-authored with Edgar Mauricio Hidalgo, Mats Isaksson, Michelle Dunn, and Jagannatha Charjee Pyaraka.

The research explores how a robot-mounted 2D LiDAR sensor can reconstruct a patient’s chest surface in 3D and automatically estimate an initial ultrasound probe position. This approach has the potential to streamline teleoperated cardiac imaging—reducing setup time and supporting more efficient remote diagnostics, particularly in settings where specialist access is limited.

Improving precision in robotic manufacturing

From the QUT Centre for Robotics, Zongyuan Zhang presented “Acoustic Feedback for Closed-Loop Force Control in Robotic Grinding”, alongside co-authors Christopher Lehnert, Will Browne, and Jonathan Roberts.

This work introduces a low-cost alternative to traditional force sensing in robotic grinding, using acoustic feedback to maintain stable and consistent material removal. By significantly reducing hardware requirements while preserving performance, the research offers a pathway to more accessible and scalable automation for industry.

Real-time perception and tracking

In another contribution, Lan Wu, Sheila Sutjipto, Jennifer Wakulicz, and Teresa Vidal Calleja presented “DisFlow: Scene Flow from Distance Field for Object Pose, Velocity Tracking, and Surface Reconstruction.”

This research advances real-time scene understanding, enabling robots to simultaneously track object pose, motion, and surface geometry. Such capabilities are critical for robots operating in dynamic, unstructured environments, where accurate perception underpins safe and effective interaction.

Leadership and global engagement

Beyond paper presentations, Professor Teresa Vidal Calleja contributed as a keynote speaker at the Workshop on Long-term Deployments in the Wild (LoWi): Perception, Learning, and Navigation, sharing insights into the challenges and opportunities of deploying robotic systems outside controlled lab environments.

ICRA also provided a valuable platform for collaboration and connection. Researchers engaged with peers from academia and industry, strengthened existing partnerships, and explored leading robotics laboratories at TU Wien. These interactions continue to play a vital role in translating research into real-world impact.

A growing international presence

The Centre’s presence at ICRA 2026 reflects the breadth and depth of its research, spanning human-centred robotics, industrial automation, and intelligent perception systems.

By contributing to one of the most prestigious conferences in the field, these researchers are not only advancing their respective domains but also strengthening Australia’s position in the global robotics ecosystem.

As collaborations deepen and new opportunities emerge, the momentum from ICRA 2026 will continue to shape the next phase of research and innovation across the Centre and its partners.

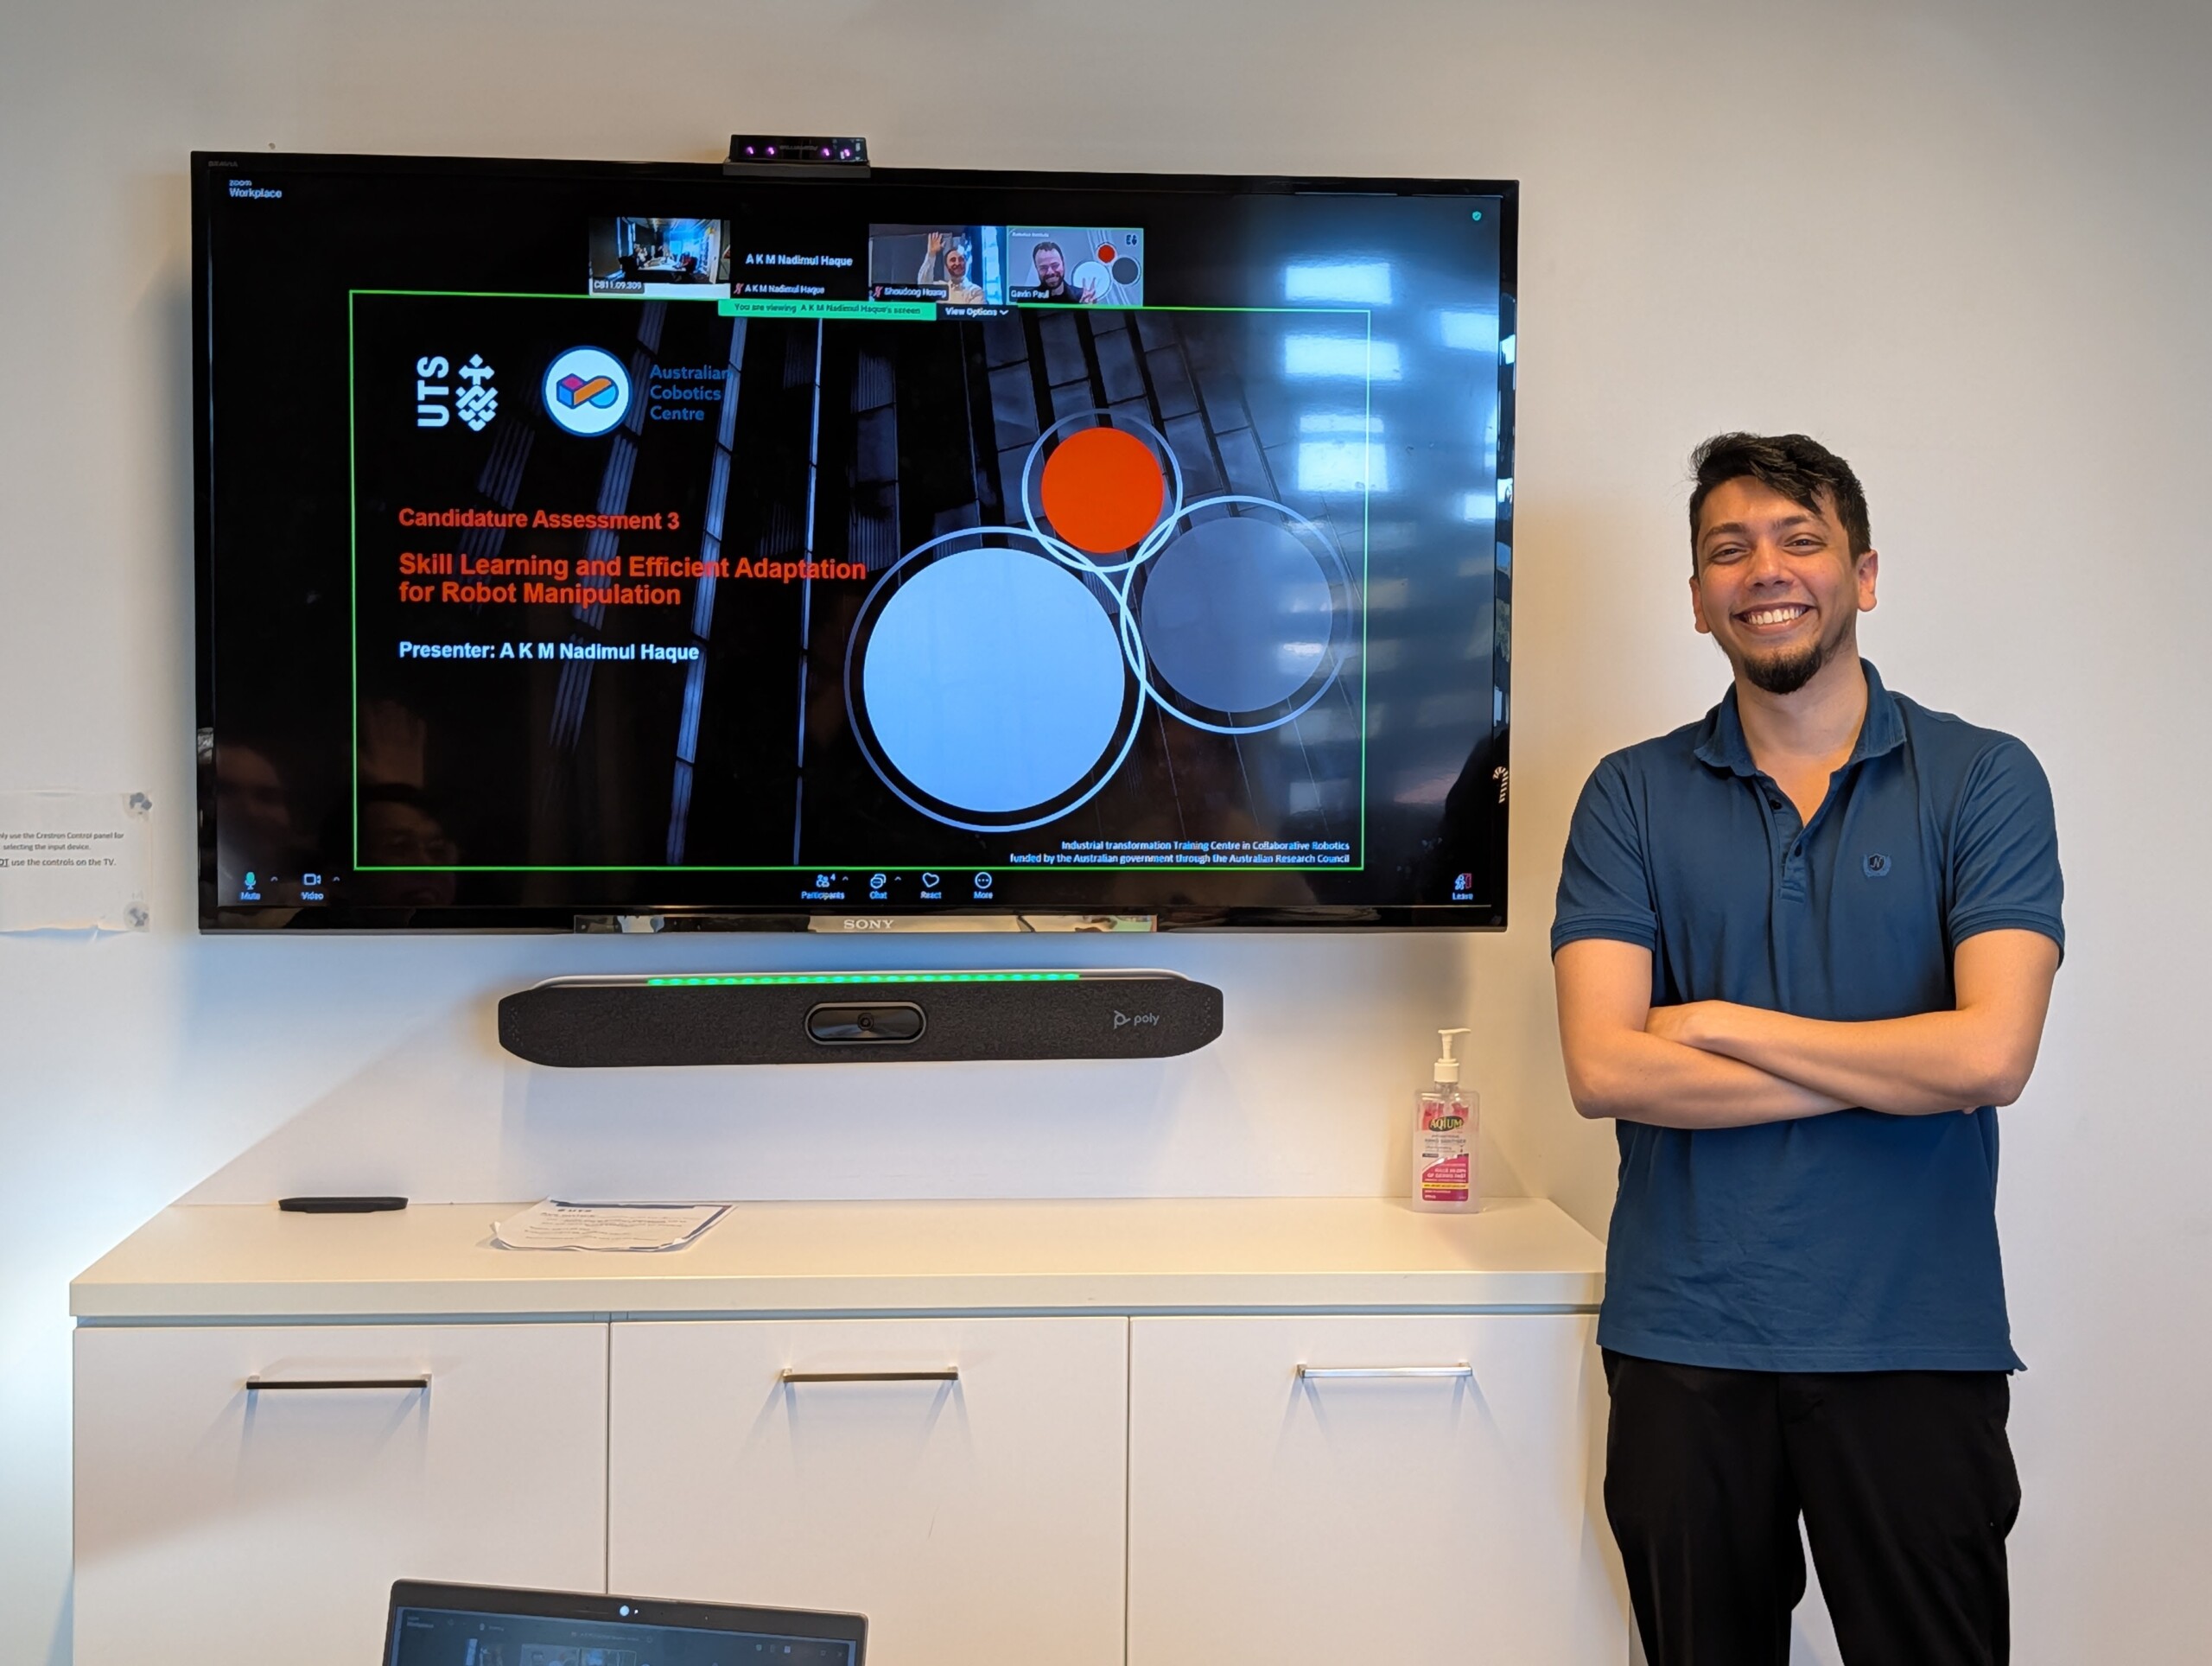
Congratulations to Nadimul Haque on the successful completion of his CA3! 

Congratulations to University of Technology Sydney PhD researcher Nadimul Haque on the successful completion of his CA3!

Nadimul’s PhD research, entitled: Skill Learning and Efficient Adaptation for Robot Manipulation, focuses on how collaborative robots can safely and intelligently perform manipulation tasks in dynamic environments. His work brings together perception, planning, situational awareness, and learning‑based control to support close human‑robot interaction in settings that extend beyond fixed, highly structured factory floors.. His work has been conducted in close collaboration with InfraBuild, ensuring the research is grounded in practical challenges and delivers meaningful impact for Australian industry.

🔗 Read more about his project: https://lnkd.in/gnGtqbN3

The CA3 marks the final milestone before PhD submission and was attended by:
Chair: Prof Shoudong Huang
Assessor: A/Prof Gavin Paul
Supervisory Panel: Prof Teresa Vidal Calleja, A/Prof Marc Carmichael, Dr Fouad (Fred) Sukkar, Dr Sheila Sutjipto

Best of luck with final submission, Nadim! We are very proud of you and look forward to seeing the impact of this work.

Well done, Nadimul!

QUTie Hits the Road: Humanoid Robotics in the Real World

QUTie Hits the Road: Humanoid Robotics in the Real World

QUT’s newest humanoid robot, QUTie, has been stepping beyond the lab and into real-world environments—supporting research, sparking conversations, and building connections across Queensland and northern New South Wales.

As part of a broader push to explore how humanoid robots can integrate into everyday life, QUTie recently joined researchers on a regional and industry engagement tour, showcasing the role robotics can play in future communities, workplaces, and industries.

Inspiring communities across Queensland

Through outreach initiatives, including visits linked to the Country Universities Centre, QUTie has been helping engage regional communities in discussions around technology adoption and innovation. These interactions are not only inspiring curiosity but also informing future research directions—grounded in real-world perspectives on how robotics can support regional and remote Australia.

By bringing a humanoid robot directly into these settings, researchers are gaining valuable insights into how people respond to emerging technologies outside controlled environments.

Robotics meets industry and design

QUTie also joined A/Prof Müge Belek Fialho Teixeira and Prof Jonathan Roberts at the Metricon Design Summit in Byron Bay, where robotics and digital innovation took centre stage.

Müge shared insights into the future of construction, exploring how robotics and digital fabrication are transforming building practices. At the same time, Jon highlighted the growing role of humanoid robots in everyday contexts—from construction sites to domestic environments—demonstrating their potential to support a wide range of tasks.

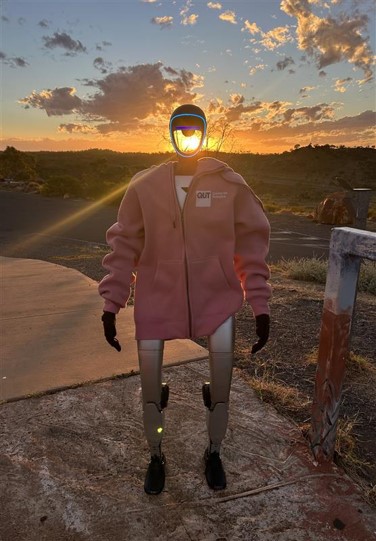
Outside the conference, QUTie made a memorable appearance at Cape Byron Lighthouse, turning heads and drawing attention from visitors—offering a glimpse of how humanoid robots are increasingly entering public spaces.

Shaping the future of humanoid research

These real-world experiences are playing a critical role in shaping QUT’s humanoid robotics research. By combining technical development with community and industry engagement, the team is building a deeper understanding of usability, trust, and application in diverse settings.

As QUTie continues to travel, interact, and learn, it represents more than a technological milestone—it’s a step toward a future where humanoid robots are part of everyday life.

Read the articles:

Australian First – Humanoid Robot competes in 5km QUT Classic

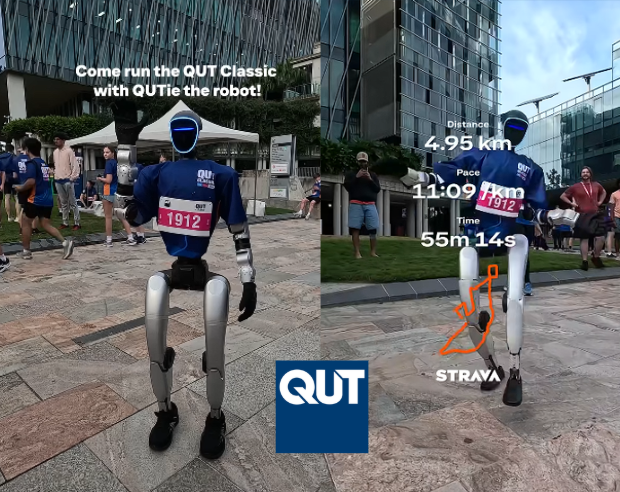
QUTie, the 130cm tall, highly agile humanoid robot, took part in the 5km run at the QUT Classic, safely and closely monitored by Jonathan Roberts, Laurianne Sitbon, and Yoann Smets. We believe this is the first time a humanoid robot has completed a race of this calibre in Australia.

Starting the race alongside everyone else at the QUT Gardens Point Campus, QUTie enjoyed a scenic run around Kangaroo Point before finishing with a final stretch through the city’s Botanic Gardens. QUTie completed the Classic in just over an hour.

Throughout the race, QUTie quickly became a crowd favourite, mingling with participants before and after the run, taking countless selfies and photos, while also showing off its amazing dance moves!

During the race, QUTie self-managed its pace and slowed down whenever its motors heated up, proving the event was not only a great photo opportunity but also an excellent way to test QUTie in the Real World.

Check out the QUT Sport post here: QUT Sport post

Congratulations to Munia Ahamed on the successful completion of her CA3!

Congratulations to University of Technology Sydney PhD researcher Munia Ahamed on the successful completion of her CA3! 🎉

Munia’s CA3 marks the final milestone ahead of her PhD submission.

Her PhD, undertaken within the Quality Assurance and Compliance Program, focuses on developing a structured quality assurance framework for human–robot collaborative manufacturing, with an emphasis on monitoring and automated documentation of cobot-enabled processes. Munia has worked closely with Cook Medical, ensuring her research directly addresses real-world manufacturing challenges and delivers practical value to industry.

🔗 Learn more about her project: https://lnkd.in/gu_mjYdy

Her work advances how manufacturers approach defect detection, classification, and prevention—bringing together human expertise and cobot precision to improve quality outcomes, reduce rework, and support more efficient production systems.

Munia is supervised by Dr. Nathalie Sick, Matthias Guertler and Mickey Clemon.

Congratulations, Munia! The whole team wishes you all the very best with your final submission — we are incredibly proud of you and look forward to seeing where you go next!