Member Login

ICRA 2026 in review

ICRA 2026: Showcasing Impact on the Global Robotics Stage

Researchers from the Australian Cobotics Centre and its partner institutions made a strong contribution to the IEEE International Conference on Robotics and Automation (ICRA) 2026, held in Vienna—one of the world’s leading forums for robotics research.

Across the week, Centre researchers presented work spanning healthcare robotics, advanced manufacturing, and real-time perception, highlighting both technical innovation and real-world application.

Advancing robotic healthcare

A key contribution came from Mariadas Capsran Roshan (Swinburne University of Technology), who presented the paper “Finding an Initial Probe Pose in Teleoperated Robotic Echocardiography via 2D LiDAR-Based 3D Reconstruction”, co-authored with Edgar Mauricio Hidalgo, Mats Isaksson, Michelle Dunn, and Jagannatha Charjee Pyaraka.

The research explores how a robot-mounted 2D LiDAR sensor can reconstruct a patient’s chest surface in 3D and automatically estimate an initial ultrasound probe position. This approach has the potential to streamline teleoperated cardiac imaging—reducing setup time and supporting more efficient remote diagnostics, particularly in settings where specialist access is limited.

Improving precision in robotic manufacturing

From the QUT Centre for Robotics, Zongyuan Zhang presented “Acoustic Feedback for Closed-Loop Force Control in Robotic Grinding”, alongside co-authors Christopher Lehnert, Will Browne, and Jonathan Roberts.

This work introduces a low-cost alternative to traditional force sensing in robotic grinding, using acoustic feedback to maintain stable and consistent material removal. By significantly reducing hardware requirements while preserving performance, the research offers a pathway to more accessible and scalable automation for industry.

Real-time perception and tracking

In another contribution, Lan Wu, Sheila Sutjipto, Jennifer Wakulicz, and Teresa Vidal Calleja presented “DisFlow: Scene Flow from Distance Field for Object Pose, Velocity Tracking, and Surface Reconstruction.”

This research advances real-time scene understanding, enabling robots to simultaneously track object pose, motion, and surface geometry. Such capabilities are critical for robots operating in dynamic, unstructured environments, where accurate perception underpins safe and effective interaction.

Leadership and global engagement

Beyond paper presentations, Professor Teresa Vidal Calleja contributed as a keynote speaker at the Workshop on Long-term Deployments in the Wild (LoWi): Perception, Learning, and Navigation, sharing insights into the challenges and opportunities of deploying robotic systems outside controlled lab environments.

ICRA also provided a valuable platform for collaboration and connection. Researchers engaged with peers from academia and industry, strengthened existing partnerships, and explored leading robotics laboratories at TU Wien. These interactions continue to play a vital role in translating research into real-world impact.

A growing international presence

The Centre’s presence at ICRA 2026 reflects the breadth and depth of its research, spanning human-centred robotics, industrial automation, and intelligent perception systems.

By contributing to one of the most prestigious conferences in the field, these researchers are not only advancing their respective domains but also strengthening Australia’s position in the global robotics ecosystem.

As collaborations deepen and new opportunities emerge, the momentum from ICRA 2026 will continue to shape the next phase of research and innovation across the Centre and its partners.
ARTICLE: The Humanoid Moment 

Written by Dr. Katia Bourahmoune, Acting Co-Lead, Quality Assurance & Compliance program. 

In April 2026, a humanoid robot crossed the finish line of a Beijing half-marathon in fifty minutes and twenty-six seconds, faster than any human being has ever run that distance [1]. Months earlier, humanoid robots had performed incredibly complex, synchronized martial arts routines [2]. As the media coverage gained widespread attention, something more interesting than this engineering achievement emerged: a question, not yet fully formed, about what kind of world we are now entering, and whether we are entering it with our eyes open. 

The choice to build robots in the human form is sometimes caricatured as a vanity of engineers or a concession to popular culture and science-fiction media, however, its philosophical wager is of considerable depth. The world into which these machines are being released (its factories, hospitals, construction sites, and even homes) was designed for users that stand upright, use two hands, and react dynamically to the world around them. 

Traditional forms of industrial and collaborative robots were built for tasks in bounded environments, e.g. a wheeled platform optimised for a warehouse floor or an articulated arm for a single weld point on an assembly line. A humanoid robot carries an inherent optimism about general physical intelligence: the bet, or perhaps ambition, that a machine capable of inhabiting the full texture of human environments can in time respond to the full texture of human need. The ancient concept of Ziran in classical Chinese thought illuminates what the designers in this field are reaching toward. Ziran is often rendered as naturalness, or the disposition of things to accord with their own nature [3]. In the context of robotics, this can be found in the idea of building machines that fit the world as it is, rather than demanding the world be remade to fit the machine. 

Humanoid robots are now operating in production environments and shipping in volumes that would have seemed premature as recently as 2023. Venture capital investment in humanoid robotics exceeded three billion dollars in 2024, with reports of multi-billion market projections for the next decade [4]. What this momentum cannot easily tell us is whether the design assumptions underlying this transition have been adequately examined. The present dominant commercial logic treats humanoid forms primarily as a means of fitting machine labour into existing human infrastructure i.e. same floor plan, same tools, and minimal workflow redesign. That is a reasonable engineering position. It may also be eclipsing, earlier than is wise, questions around whether the humanoid is best understood as a substitute for human presence or as a platform for augmenting it. 

It is worth noting that the world these machines are being designed to inhabit was itself built around the human body. Every dimension of that infrastructure, accumulated across two centuries of industrial development, was calibrated to the physical limits and capabilities of the biological human form. While previous waves of automation reshaped work around the machine, the humanoid, at least in aspiration, inverts that relationship. In doing so, it raises a concern that the industrial revolution never had occasion to face: What becomes of the human body’s centrality to working life when the physical form that justified building the world around it can be replicated, scaled, and indefinitely reproduced? That this question is now being asked simultaneously in boardrooms, parliaments, and papal encyclicals is perhaps the clearest measure of its weight [5].  

What the field of collaborative robotics has understood for some time (and what the humanoid moment is now forcing into general visibility) is that matching human physical capability, however necessary, is not sufficient. Harder questions concern the relationship between human and robot: what kind of human-robot partnership produces durable, humane, and useful outcomes, and under what conditions workers can reasonably extend trust to machines working beside them. Those questions shaped decades of research into human-robot interaction and collaboration and the work the Australian Cobotics Centre has been part of since 2021. How much humanoids come to define the next chapter of that work is ultimately a question research and humanity will have to answer. 


Call for Participation

The Australian Cobotics Centre is calling for experts across academia, industry, and government to participate in a research study at the University of Technology Sydney aimed at developing a clearer definition of collaborative robots. Participation involves an online discussion followed by a brief activity to rate statements about cobots. Your input will directly inform how the field defines and frames human–robot collaboration. 

More information and EOI here:  EOI and Consent Form (https://forms.office.com/r/YSYQPWqD8X) 


References and Further Reading:  

[1] Harmon, K. (2026). A humanoid robot beat the human half-marathon record at a Beijing race. But what did it actually prove? Scientific American.  

[2] Unitree Robotics. (2026). Kung fu meets spring: Unitree Spring Festival Gala robots present “Cyber Real Kung Fu” in the year of the horse [Press release]. PR Newswire.  

[3] Cleary, T. (Trans.). (1992). The essential Tao: An initiation into the heart of Taoism through the authentic Tao Te Ching and the inner teachings of Chuang-tzu. HarperCollins.  

[4] Goldman Sachs. (2024). Humanoid robots: A $38 billion market by 2035. Goldman Sachs Research.  

[5] Leo XIV. (2026). Magnifica Humanitas [Encyclical letter]. Dicastery for Communication, Holy See.  


DIS Honourable Mention for Designing Socio-Technical Robotic Systems team

Congratulations to Jasper Vermeulen and co-authors (Glenda Caldwell, Müge Belek Fialho Teixeira, Alan Burden, and Matthias Guertler) on their Honourable Mention for their paper at the ACM DIS Conference.

“The Invisible Work of Robotic Surgery: How Specialists Support, Shoulder, and Sustain Human-Robot Collaboration” has been recognised with an Honourable Mention Award!

The paper is one of 47 Honourable Mentions selected alongside 16 Best Papers from 1,154 submissions, placing it in the top ~5% of the program.

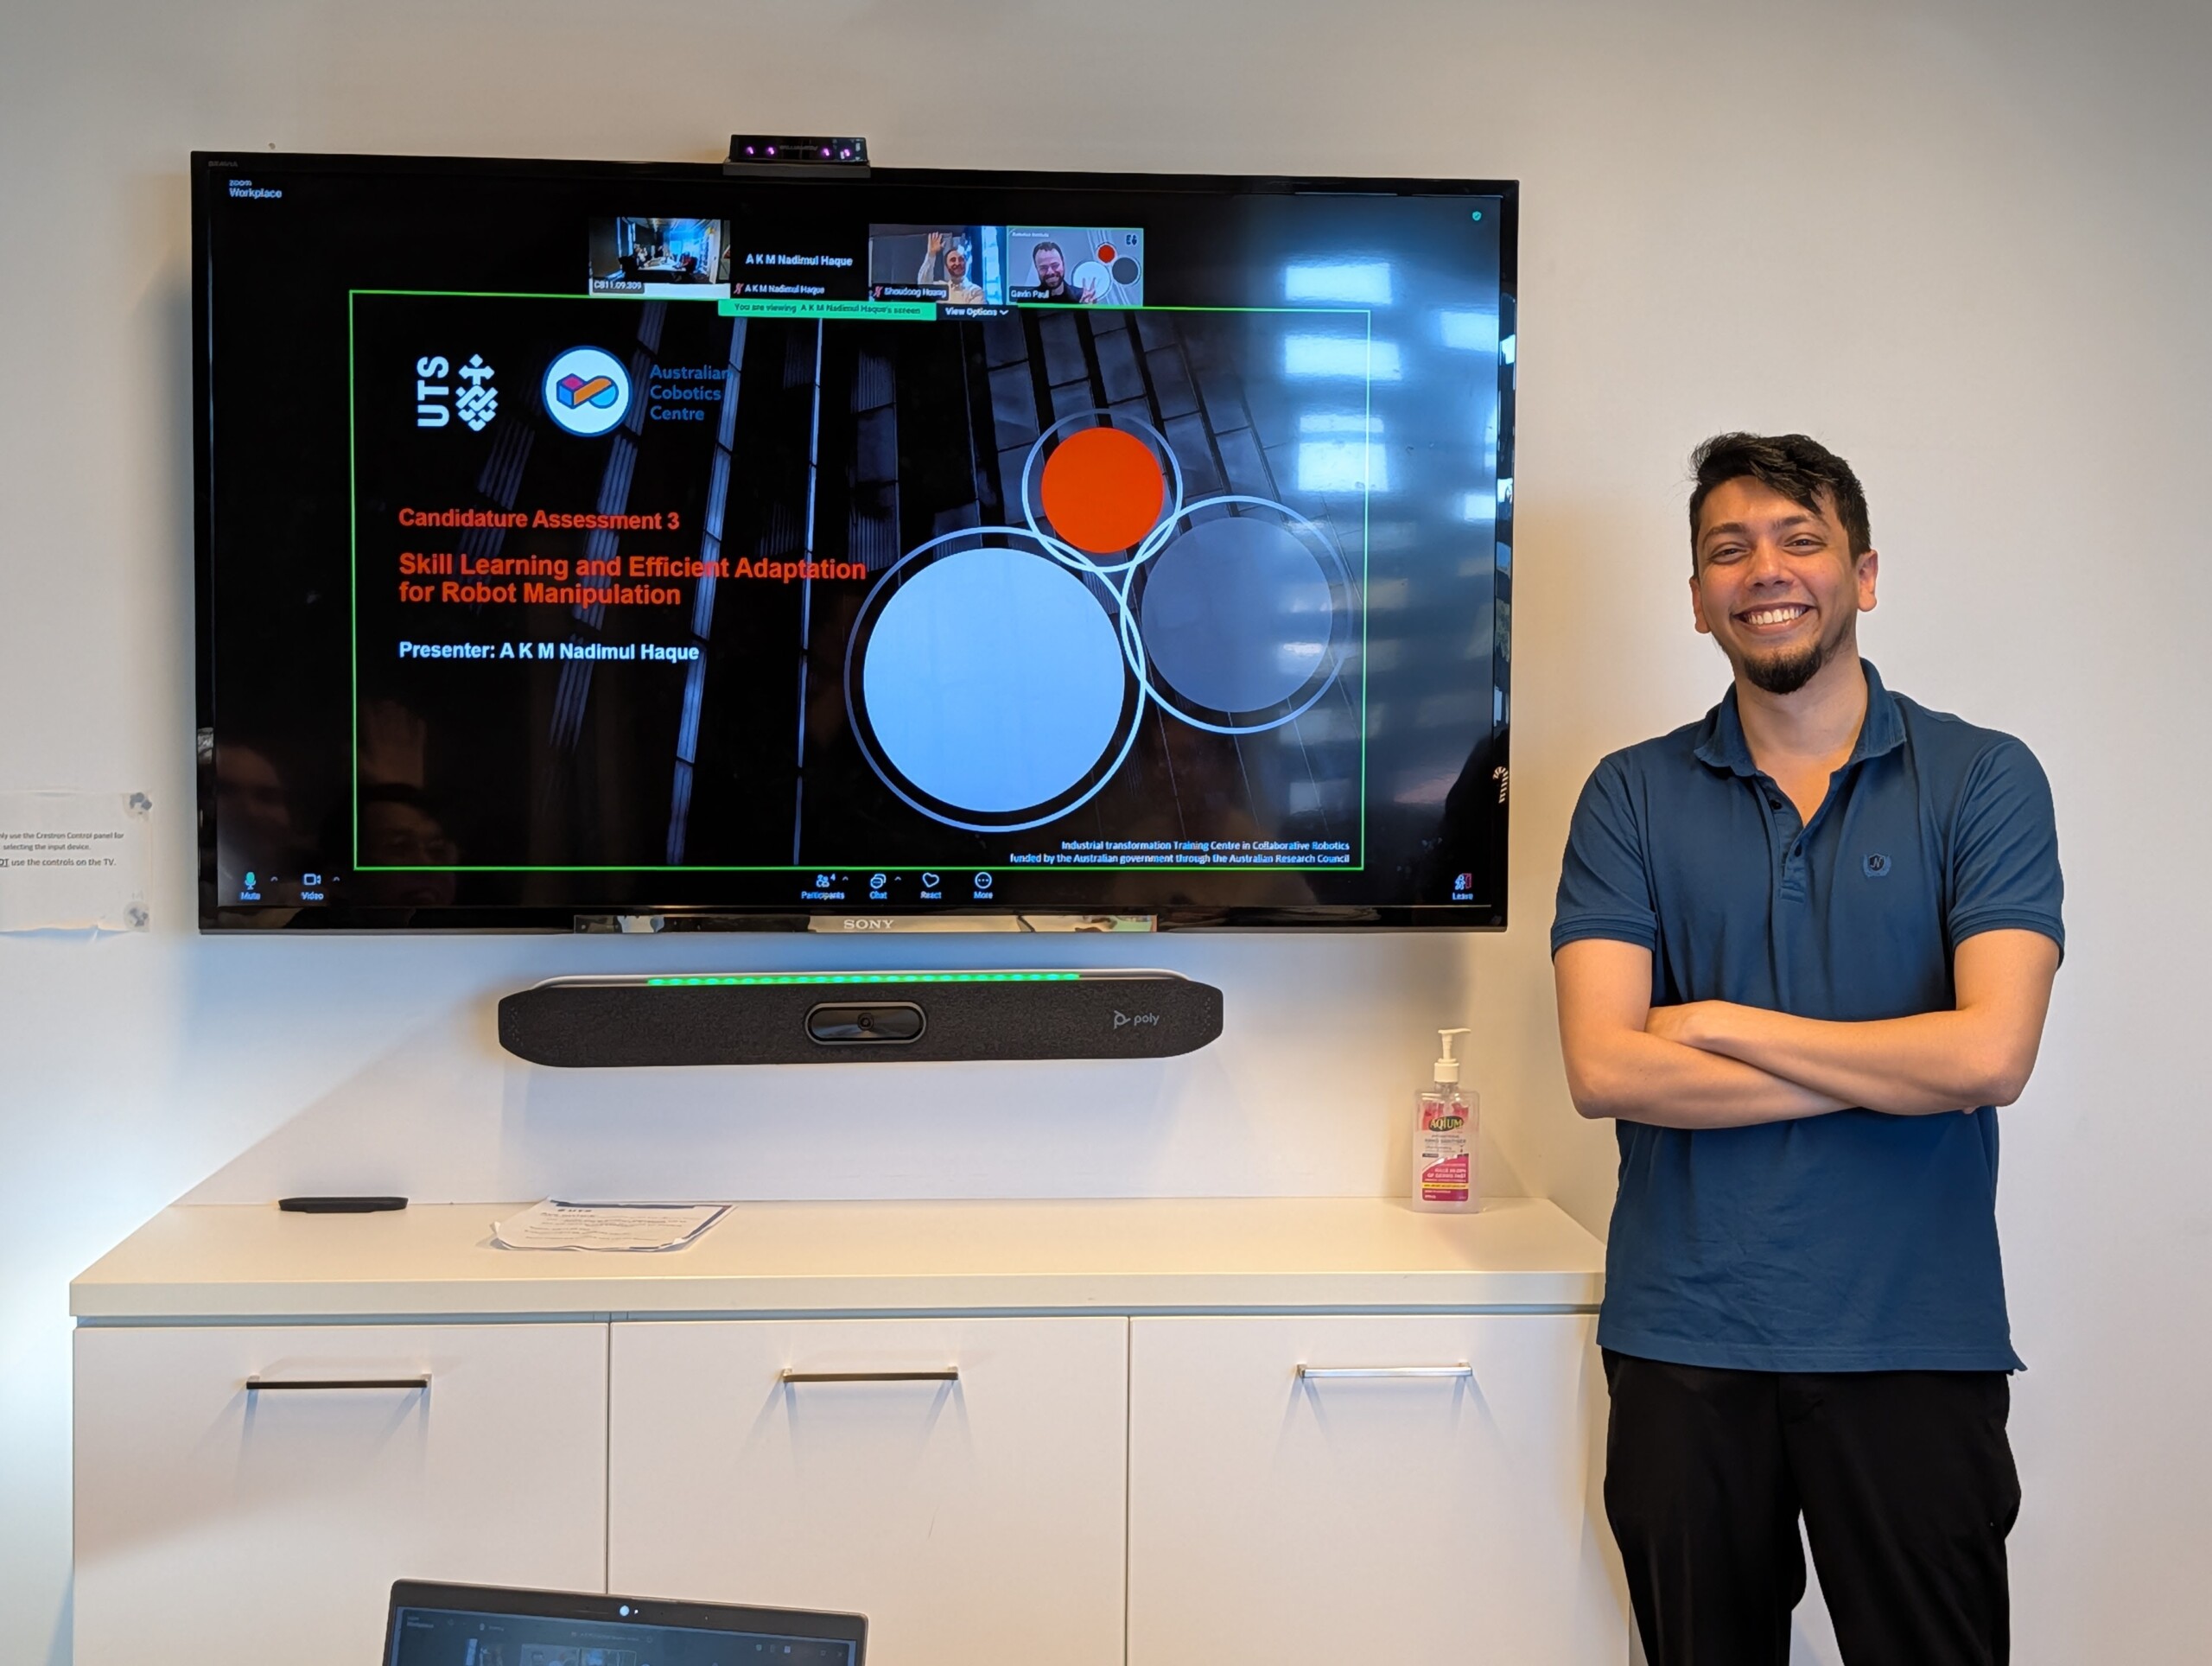
Congratulations to Nadimul Haque on the successful completion of his CA3! 

Congratulations to University of Technology Sydney PhD researcher Nadimul Haque on the successful completion of his CA3!

Nadimul’s PhD research, entitled: Skill Learning and Efficient Adaptation for Robot Manipulation, focuses on how collaborative robots can safely and intelligently perform manipulation tasks in dynamic environments. His work brings together perception, planning, situational awareness, and learning‑based control to support close human‑robot interaction in settings that extend beyond fixed, highly structured factory floors.. His work has been conducted in close collaboration with InfraBuild, ensuring the research is grounded in practical challenges and delivers meaningful impact for Australian industry.

🔗 Read more about his project: https://lnkd.in/gnGtqbN3

The CA3 marks the final milestone before PhD submission and was attended by:
Chair: Prof Shoudong Huang
Assessor: A/Prof Gavin Paul
Supervisory Panel: Prof Teresa Vidal Calleja, A/Prof Marc Carmichael, Dr Fouad (Fred) Sukkar, Dr Sheila Sutjipto

Best of luck with final submission, Nadim! We are very proud of you and look forward to seeing the impact of this work.

Well done, Nadimul!

QUTie Hits the Road: Humanoid Robotics in the Real World

QUTie Hits the Road: Humanoid Robotics in the Real World

QUT’s newest humanoid robot, QUTie, has been stepping beyond the lab and into real-world environments—supporting research, sparking conversations, and building connections across Queensland and northern New South Wales.

As part of a broader push to explore how humanoid robots can integrate into everyday life, QUTie recently joined researchers on a regional and industry engagement tour, showcasing the role robotics can play in future communities, workplaces, and industries.

Inspiring communities across Queensland

Through outreach initiatives, including visits linked to the Country Universities Centre, QUTie has been helping engage regional communities in discussions around technology adoption and innovation. These interactions are not only inspiring curiosity but also informing future research directions—grounded in real-world perspectives on how robotics can support regional and remote Australia.

By bringing a humanoid robot directly into these settings, researchers are gaining valuable insights into how people respond to emerging technologies outside controlled environments.

Robotics meets industry and design

QUTie also joined A/Prof Müge Belek Fialho Teixeira and Prof Jonathan Roberts at the Metricon Design Summit in Byron Bay, where robotics and digital innovation took centre stage.

Müge shared insights into the future of construction, exploring how robotics and digital fabrication are transforming building practices. At the same time, Jon highlighted the growing role of humanoid robots in everyday contexts—from construction sites to domestic environments—demonstrating their potential to support a wide range of tasks.

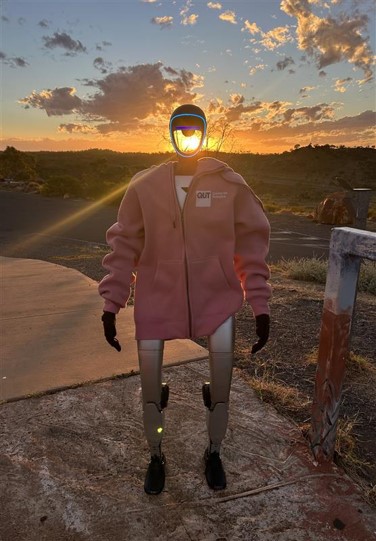
Outside the conference, QUTie made a memorable appearance at Cape Byron Lighthouse, turning heads and drawing attention from visitors—offering a glimpse of how humanoid robots are increasingly entering public spaces.

Shaping the future of humanoid research

These real-world experiences are playing a critical role in shaping QUT’s humanoid robotics research. By combining technical development with community and industry engagement, the team is building a deeper understanding of usability, trust, and application in diverse settings.

As QUTie continues to travel, interact, and learn, it represents more than a technological milestone—it’s a step toward a future where humanoid robots are part of everyday life.

Read the articles:

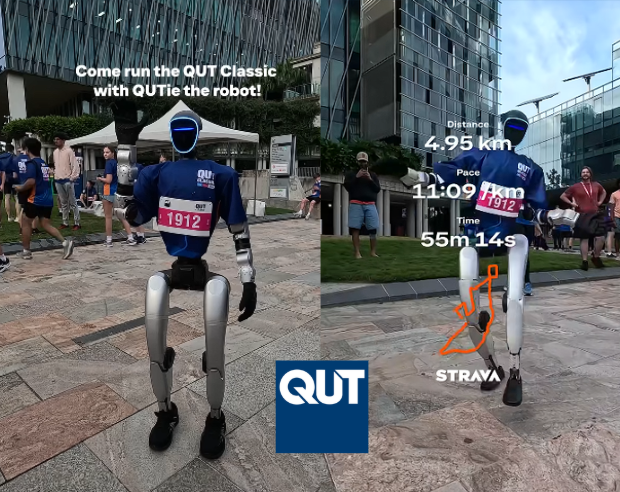
Australian First – Humanoid Robot competes in 5km QUT Classic

QUTie, the 130cm tall, highly agile humanoid robot, took part in the 5km run at the QUT Classic, safely and closely monitored by Jonathan Roberts, Laurianne Sitbon, and Yoann Smets. We believe this is the first time a humanoid robot has completed a race of this calibre in Australia.

Starting the race alongside everyone else at the QUT Gardens Point Campus, QUTie enjoyed a scenic run around Kangaroo Point before finishing with a final stretch through the city’s Botanic Gardens. QUTie completed the Classic in just over an hour.

Throughout the race, QUTie quickly became a crowd favourite, mingling with participants before and after the run, taking countless selfies and photos, while also showing off its amazing dance moves!

During the race, QUTie self-managed its pace and slowed down whenever its motors heated up, proving the event was not only a great photo opportunity but also an excellent way to test QUTie in the Real World.

Check out the QUT Sport post here: QUT Sport post

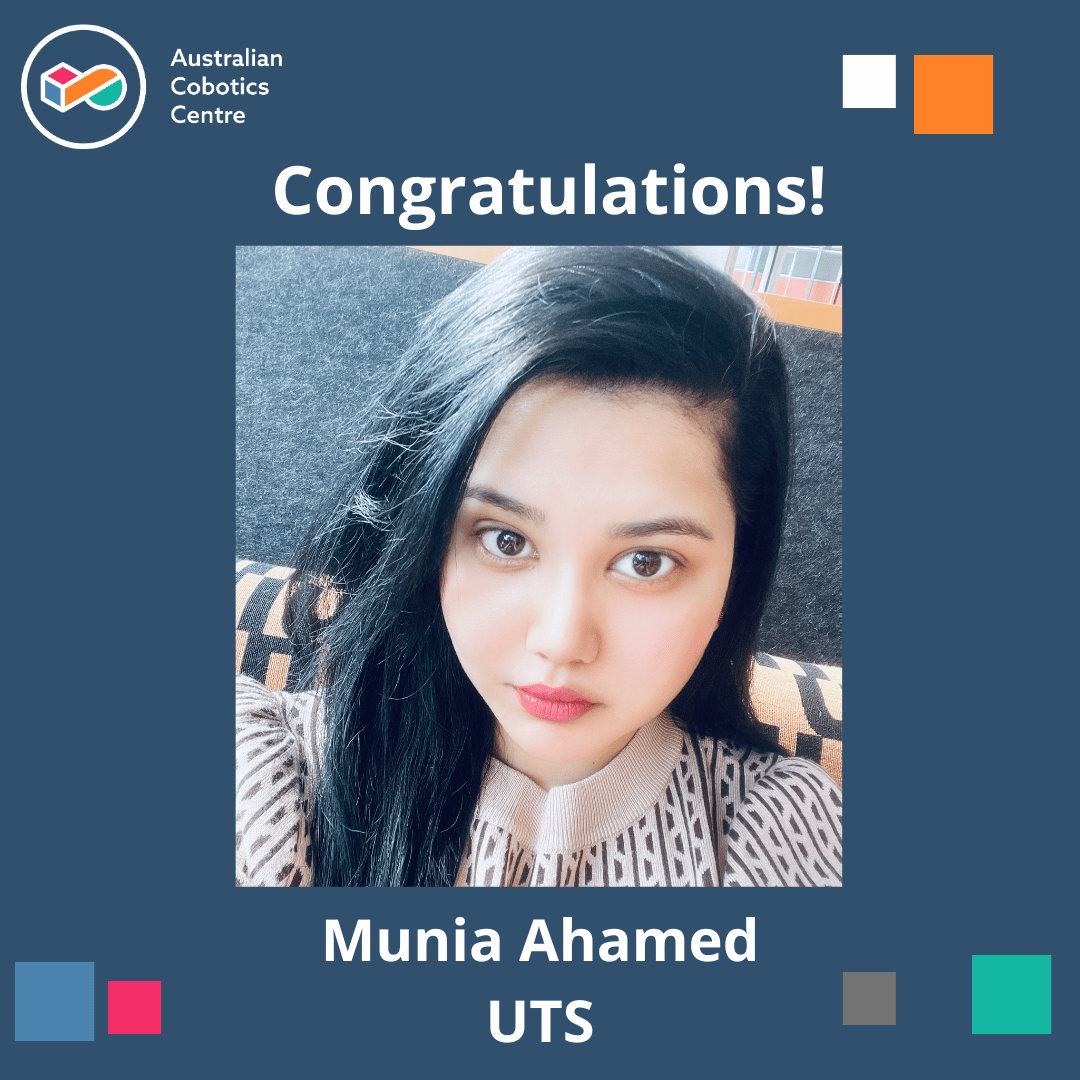
Congratulations to Munia Ahamed on the successful completion of her CA3!

Congratulations to University of Technology Sydney PhD researcher Munia Ahamed on the successful completion of her CA3! 🎉

Munia’s CA3 marks the final milestone ahead of her PhD submission.

Her PhD, undertaken within the Quality Assurance and Compliance Program, focuses on developing a structured quality assurance framework for human–robot collaborative manufacturing, with an emphasis on monitoring and automated documentation of cobot-enabled processes. Munia has worked closely with Cook Medical, ensuring her research directly addresses real-world manufacturing challenges and delivers practical value to industry.

🔗 Learn more about her project: https://lnkd.in/gu_mjYdy

Her work advances how manufacturers approach defect detection, classification, and prevention—bringing together human expertise and cobot precision to improve quality outcomes, reduce rework, and support more efficient production systems.

Munia is supervised by Dr. Nathalie Sick, Matthias Guertler and Mickey Clemon.

Congratulations, Munia! The whole team wishes you all the very best with your final submission — we are incredibly proud of you and look forward to seeing where you go next!

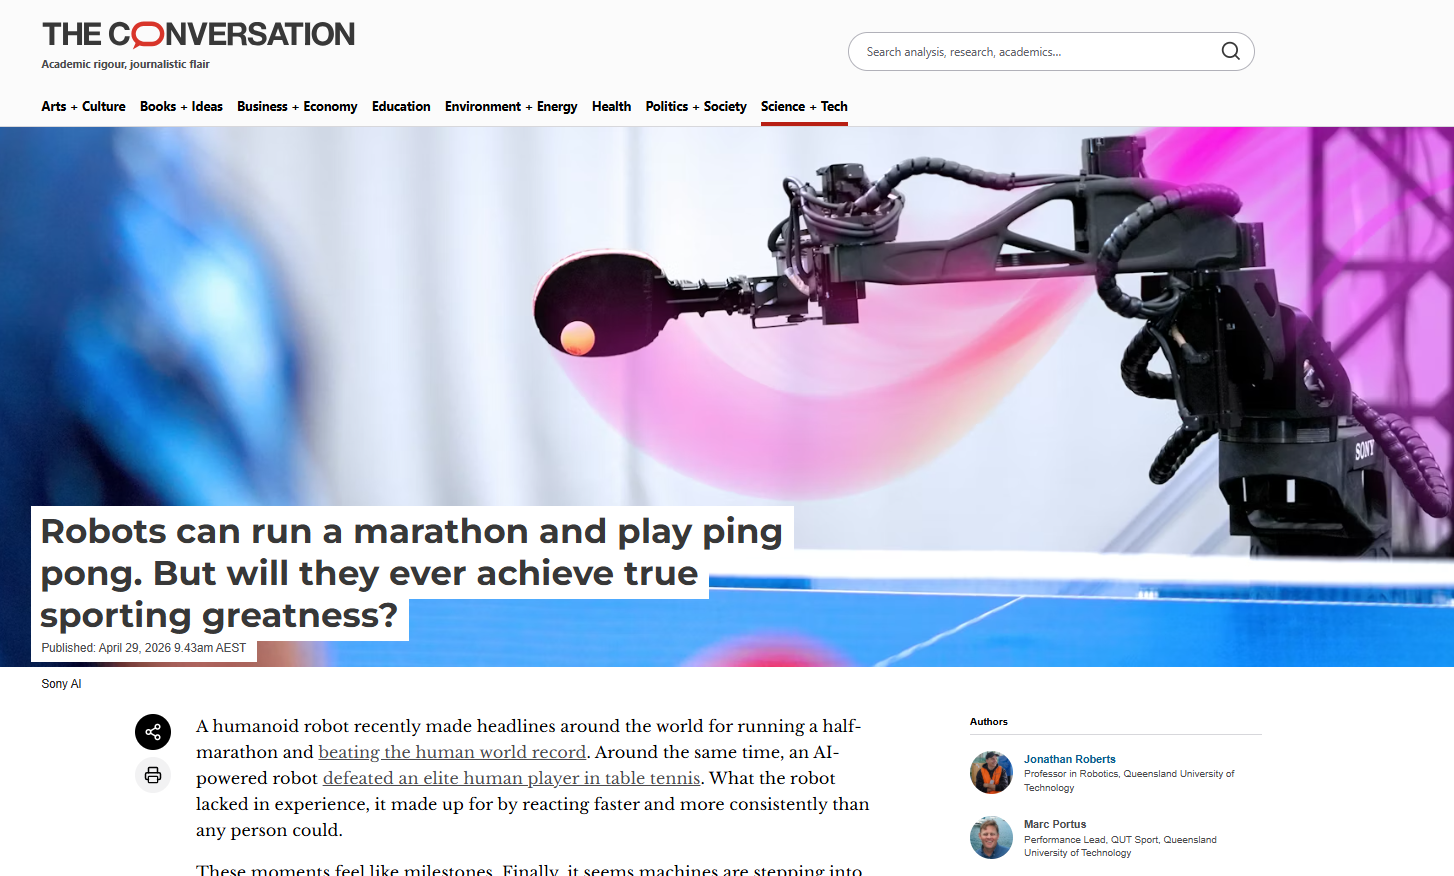
Robots can run a marathon and play ping pong. But will they ever achieve true sporting greatness?

An article in The Conversation, co-authored by Centre Director Prof Jon Roberts and QUT Sport’s Marc Portus, explores the rapid rise of robots in sport, from marathon-running humanoids to robots competing with elite table tennis players.

The piece highlights that while robots can excel in precision, speed, and consistency, true sporting greatness goes beyond technical ability. Human performance is shaped by creativity, context, and decision-making under pressure, all elements that remain difficult to replicate. 

They argue the real opportunity is in using robotics to enhance training and better understand human performance, positioning robots as valuable partners in the future of sport.

READ THE ARTICLE


Robotics Australia Group Excellence Awards

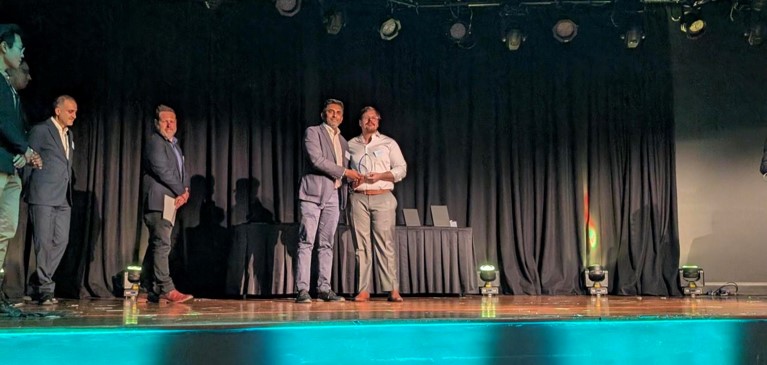
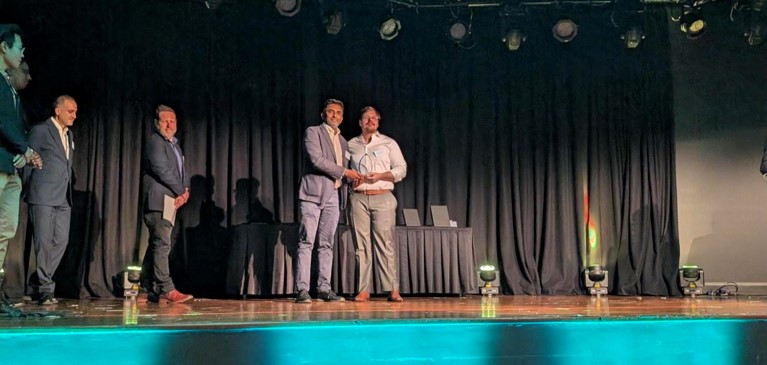
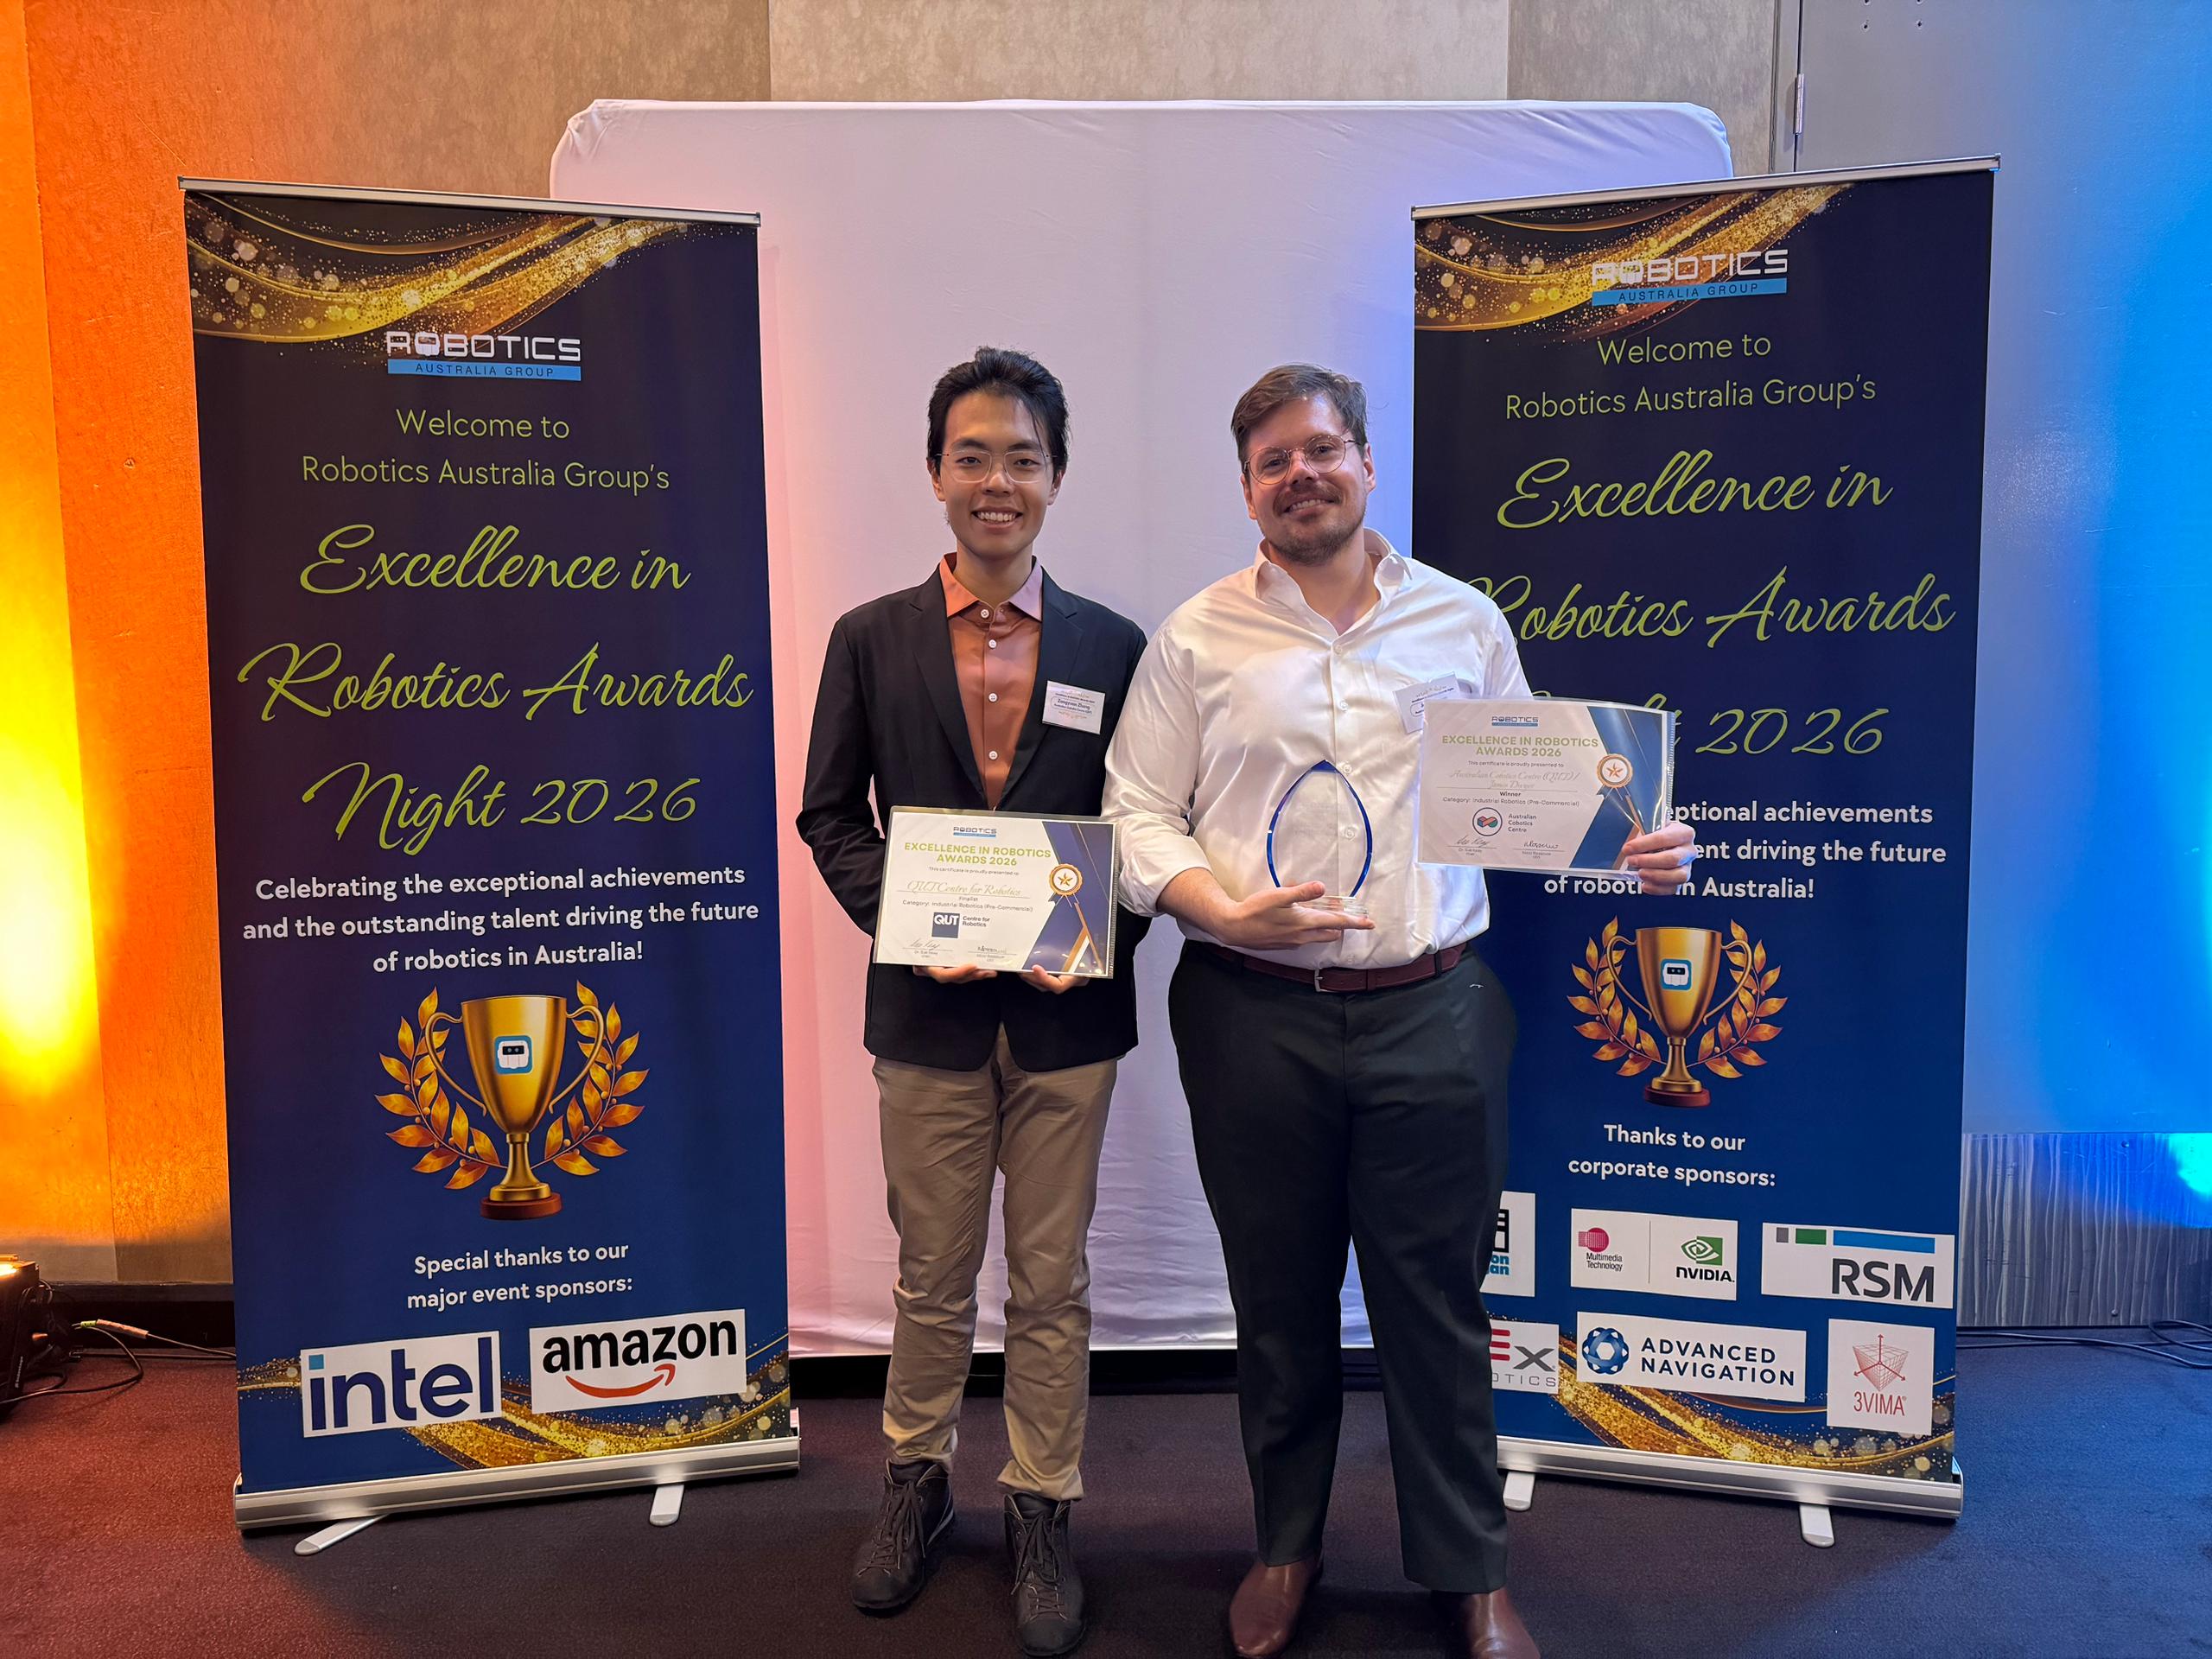
We’re proud to congratulate James Dwyer on winning the Robotics Australia Group Excellence in Robotics Award (Industrial Robotics – Pre‑commercial). This national recognition highlights his innovative work on the Kinematic Puppet.

Congratulations also to our outstanding finalists:

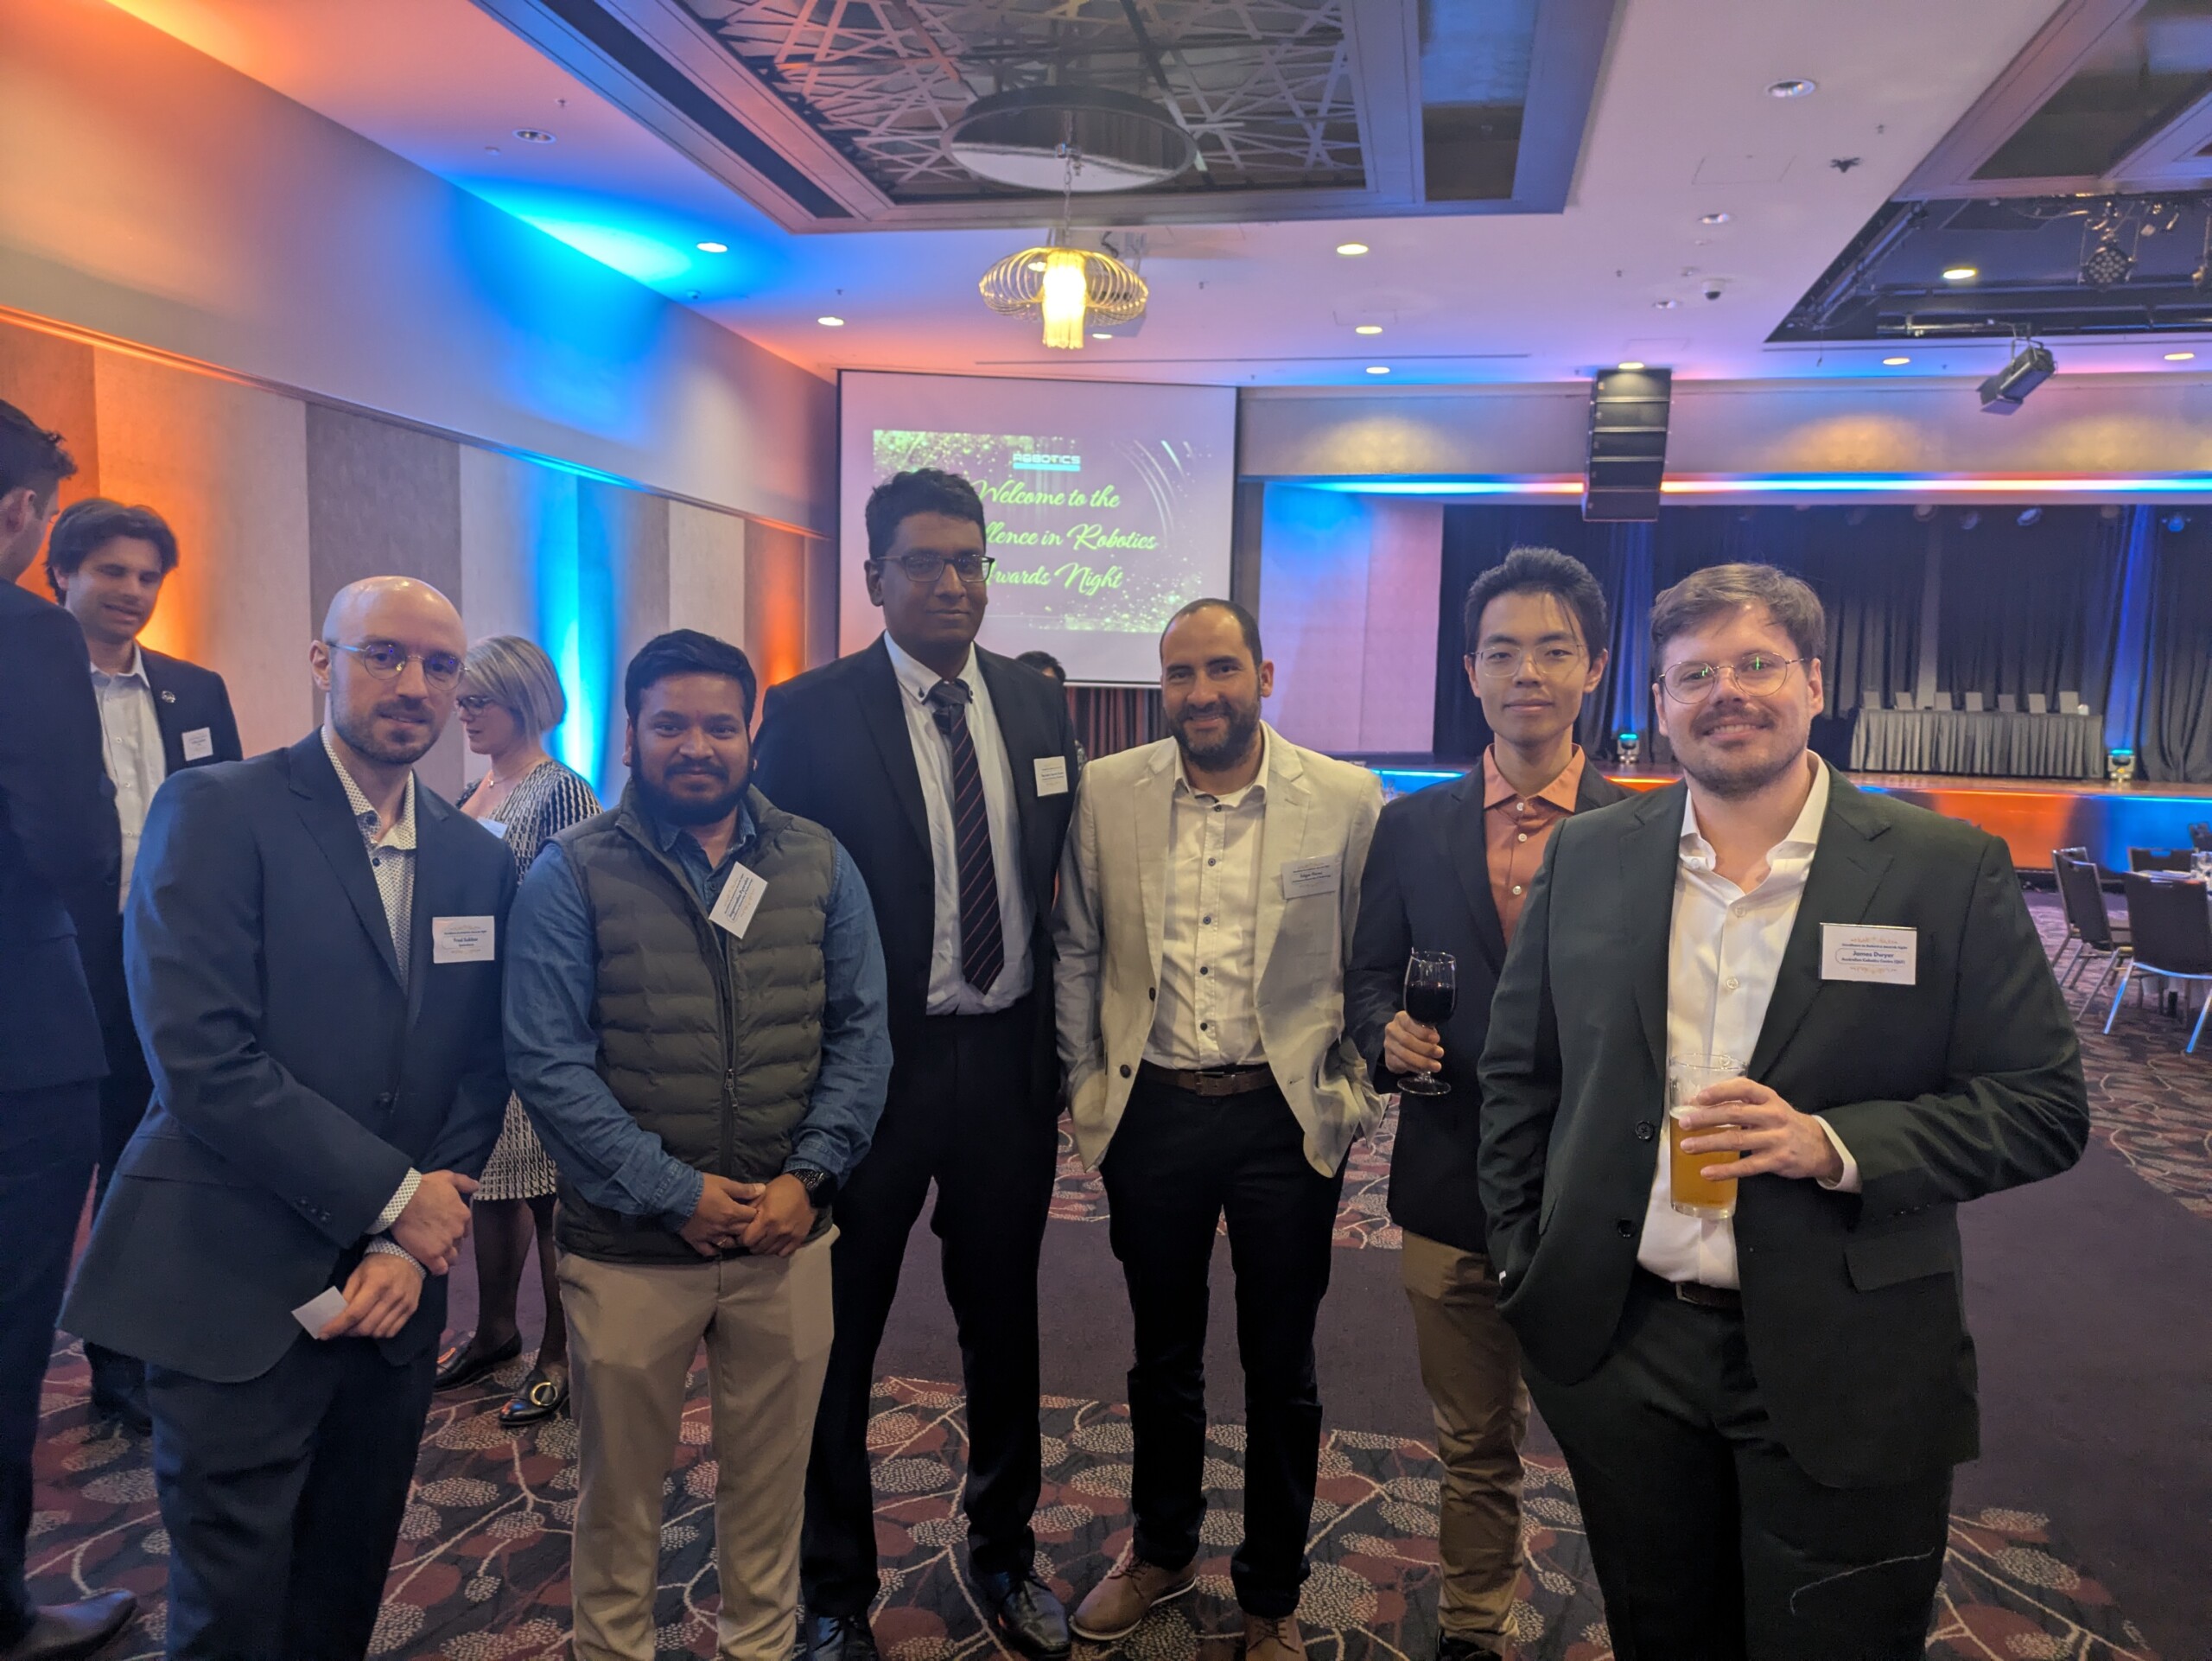
The event also sparked a mini ACC reunion, with former UTS postdoc Fouad (Fred) Sukkar joining the celebrations.

Thank you to the Robotics Australia Group, especially former CEO Nicci Rossouw and Chair Sue Keay, for hosting a fantastic awards night and expo.

Read more: Robotics Australia Group


A Cost-Effective Path to Better Finishing: Robots That Learn Through Sound

Industrial automation has traditionally been built around a fundamental limitation: robots cannot “feel”. Sensing physical interaction with a workpiece or environment has historically required expensive hardware, making such capabilities impractical for many industrial systems. As a result, conventional industrial robots typically operate in isolation, executing preprogrammed motions without direct awareness of the forces they encounter. 

The development of collaborative robots (cobots) introduced the ability to sense internal forces and detect collisions, allowing for safer human-robot interaction. However, true physical awareness requires external sensors. When equipped with exteroceptive sensors, such as those that measure forces or vibrations, robots can respond to external conditions like a changing workpiece. This capability expands robotic automation into applications that require both force sensitivity and precision, including complex finishing operations such as grinding and polishing. 

Grinding remains one of the most physically demanding tasks in metal fabrication. The process requires a balance between force and precision; too little pressure slows production, while too much risks damaging the part or wearing down the tool prematurely. These characteristics make grinding a promising candidate for automation. Many manufacturers pursue robotic grinding not only to address rising labour costs and workforce shortages, but also to achieve process consistency and repeatability. 

However, implementing robotic grinding typically requires high-end sensing hardware. These systems often rely on force/torque sensors to measure the interaction between the tool and the workpiece, enabling robots to maintain the controlled force necessary for precision finishing. These sensors can cost upwards of $4,400 USD. For many small and medium-sized enterprises (SMEs), particularly in Australia, this cost represents a significant barrier to entry, turning automation into a financial hurdle rather than a competitive advantage. 

Recent research by PhD candidate, Zongyuan Zhang and his supervisory team suggests that robots may not need expensive sensors to achieve force awareness. Human operators performing grinding tasks often rely on subtle auditory cues, like the pitch and vibration of the tool, to judge the quality of contact with the material. Experienced machinists can detect changes in force or tool wear simply by listening to the sound of the process. Inspired by this intuition, researchers have begun exploring whether similar information can be extracted using low-cost acoustic sensing combined with machine learning. 

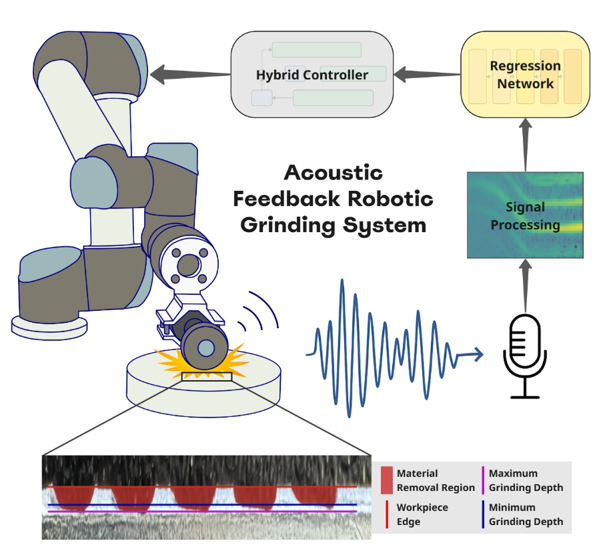
The proposed Acoustic Feedback Robotic Grinding (AFRG) system (see Figure 1) demonstrates how this approach can work in practice. Instead of measuring force directly, the system monitors the acoustic signature of the grinding process. A single contact microphone is mounted to the tool bracket, capturing vibrations transmitted through the structure of the tool while filtering out much of the ambient noise present on a factory floor. 

The captured signal is processed by a specialised neural network known as PSDRegNet, a two-dimensional convolutional neural network designed to estimate the grinding force. By learning the complex relationship between acoustic patterns and grinding forces, the model can estimate the interaction force in real time. This data can then be used to adjust the robot’s behaviour online. Since the system learns this relationship directly from data, it avoids the need for rigid mathematical models that would typically govern robotic finishing processes. This flexibility allows the same system to adapt more easily to different materials, tools, and process conditions, reducing the time and engineering effort required to reconfigure robotic cells for new tasks. 

Another challenge in robotic finishing is tool degradation. As grinding discs wear down or become clogged with material, their cutting efficiency declines. Robots that rely on fixed paths or constant force setpoints often struggle to compensate for this change, leading to inconsistent material removal over time. In experimental trials conducted on hardened stainless steel, a material known for accelerating tool wear, the AFRG system demonstrated a fourfold improvement in grinding consistency compared to traditional force-based control. Since the acoustic model captures tangential force information closely related to the material removal rate, the system can maintain a stable finishing process even as the physical properties of the grinding disc change. 

Figure 1: The Acoustic Feedback Robotic Grinding System (AFRG) leverages acoustic signals for closed-loop force control in robotic grinding. Rather than relying on costly force sensors, AFRG uses a low-cost contact microphone to estimate the grinding force. The process involves recording audio, processing the signals, and applying regression techniques to estimate the force, which is then used to regulate the grinding process. Image courtesy of https://arxiv.org/html/2602.20596  

The implications extend beyond grinding. If meaningful process information can be extracted from inexpensive sensors such as microphones, accelerometers, or cameras, machine learning may enable a new generation of low-cost perceptual capabilities for industrial robots. Instead of relying on specialised hardware for every sensing task, robots could infer key physical variables from readily available signals. 

For the Australian Cobotics Centre, this approach demonstrates a cost-effective pathway for quickly upgrading existing industrial infrastructure, something important for many Australian SMEs. Many legacy robots are position-controlled, following a set of predefined positions without sensing the forces involved in the task. Retrofitting these systems with force sensors can be costly, but in contrast, an acoustic sensing system can be integrated with minimal modifications, offering closed-loop force control at a fraction of the cost. 

More broadly, this work challenges the assumption that precision automation must rely on expensive hardware. By combining off-the-shelf sensors with machine learning, it becomes possible to convert robots from pre-programmed machines into adaptive systems capable of responding to their environment. 


Acoustic Feedback for Closed-Loop Force Control in Robotic Grinding, Zongyuan Zhang*, Christopher Lehnert, Will Browne, Jonathan Roberts