


POSTED: 03 Dec, 2025
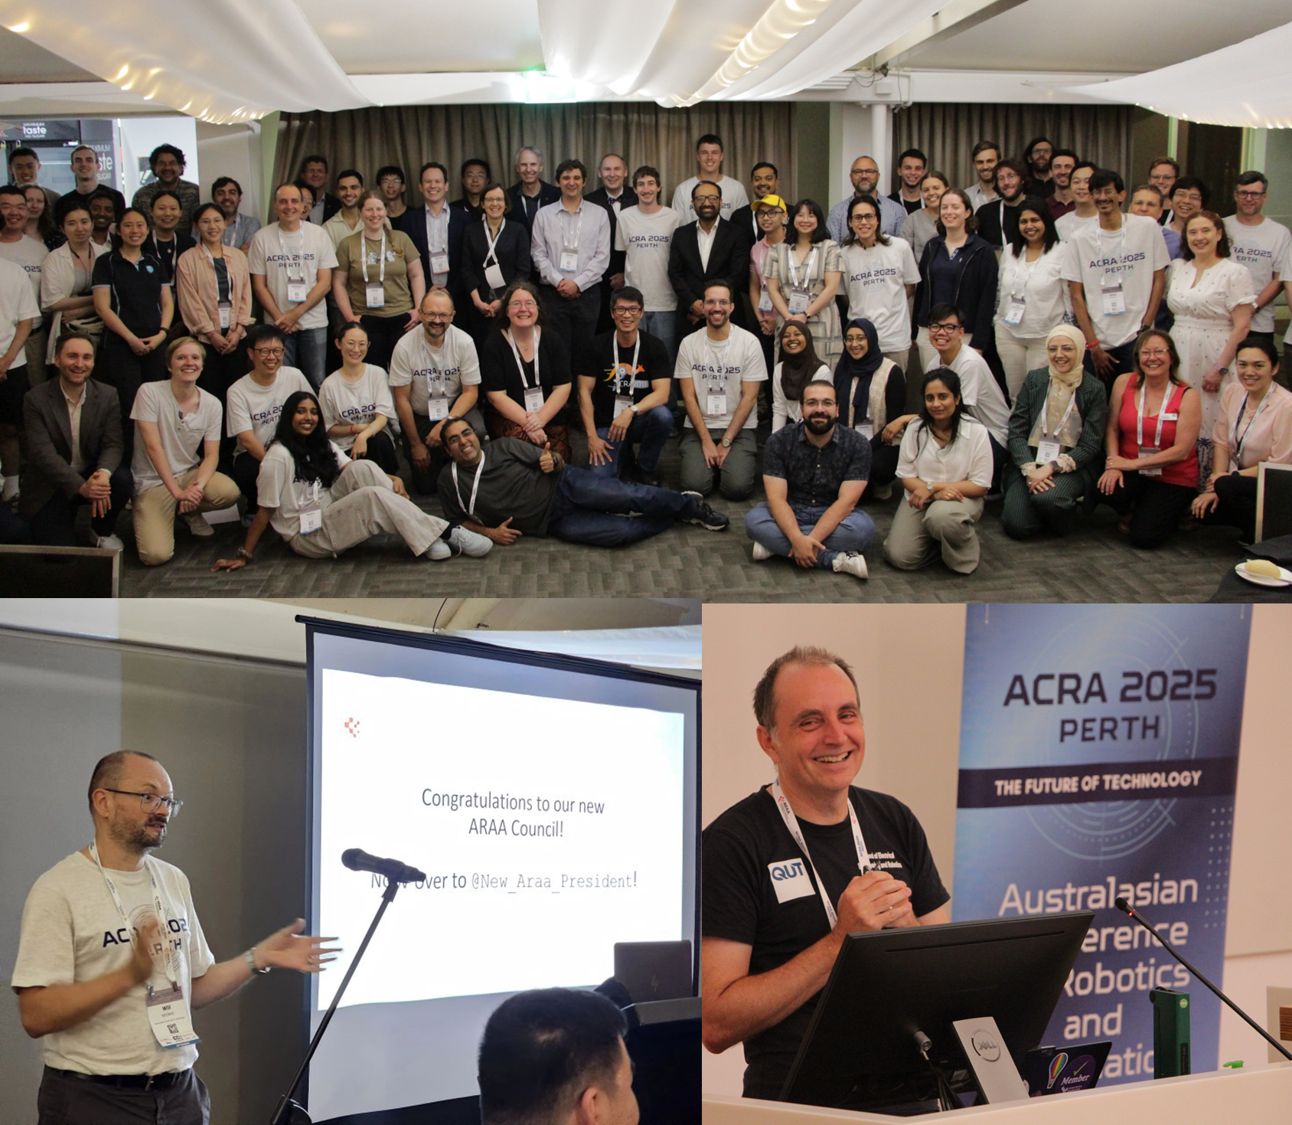
The 27th Australian Conference on Robotics and Automation (ACRA) was held at Edith Cowan University in Western Australia from 1-3rd December, bringing together leading researchers and industry innovators. The Australian Cobotics Centre proudly contributed five accepted papers, highlighting advances in collaborative robotics, humanoid systems, and AI-driven decision-making:
- Solomonoff-Inspired Hypothesis Ranking with LLMs for Prediction Under Uncertainty
Authors: Josh Barber, Rourke Young, Cameron Coombe, Will Browne (QUT) - User Preference for Handle Force Transformation for Quadruped Guide Robot
Authors: Luke Bouttell, Marc Carmichael, Sarath Kodagoda (UTS) - Robots Watching Robots – Pose Estimation Applied to Humanoid Robots
Authors: James Matthew Young, Jonathan Roberts (QUT) - Big Robots, Small Tasks – Task Scale Reduction Using a Simple Pantograph Mechanism
Authors: Sean Burgess, Braydon Pithie, Jonathan Roberts (QUT) - Training Humanoid Robots to Walk in Lunar Gravity Using Reinforcement Learning
Authors: Benjamin Klein, Jonathan Roberts (QUT)
The conference concluded with a highlight for the Centre: Professor Will Browne was announced as the new President of the Australian Robotics and Automation (ARAA) Association.
Recent News
Humanoid Robotics in the Spotlight: Australian Cobotics Centre Researchers Share Expertise with National Audiences
Humanoid Robotics in the Spotlight: Australian Cobotics Centre Researchers Share Expertise with National Audiences Humanoid robotics has captured ...
What is Mathematical Optimisation Actually Doing? A Physical Picture of Finding the Shortest Distance Between Shapes
Written by Louis Fernandez, PhD Researcher, based at UTS and part of the Human-Robot Interaction program. Mathematical optimisation often comes acros ...
MegaTrans 2026: Where Robotics Meets the Future of Logistics
MegaTrans 2026: Where Robotics Meets the Future of Logistics As Australia's freight, warehousing and logistics sectors face growing pressure to imp ...