


POSTED: 03 Dec, 2025
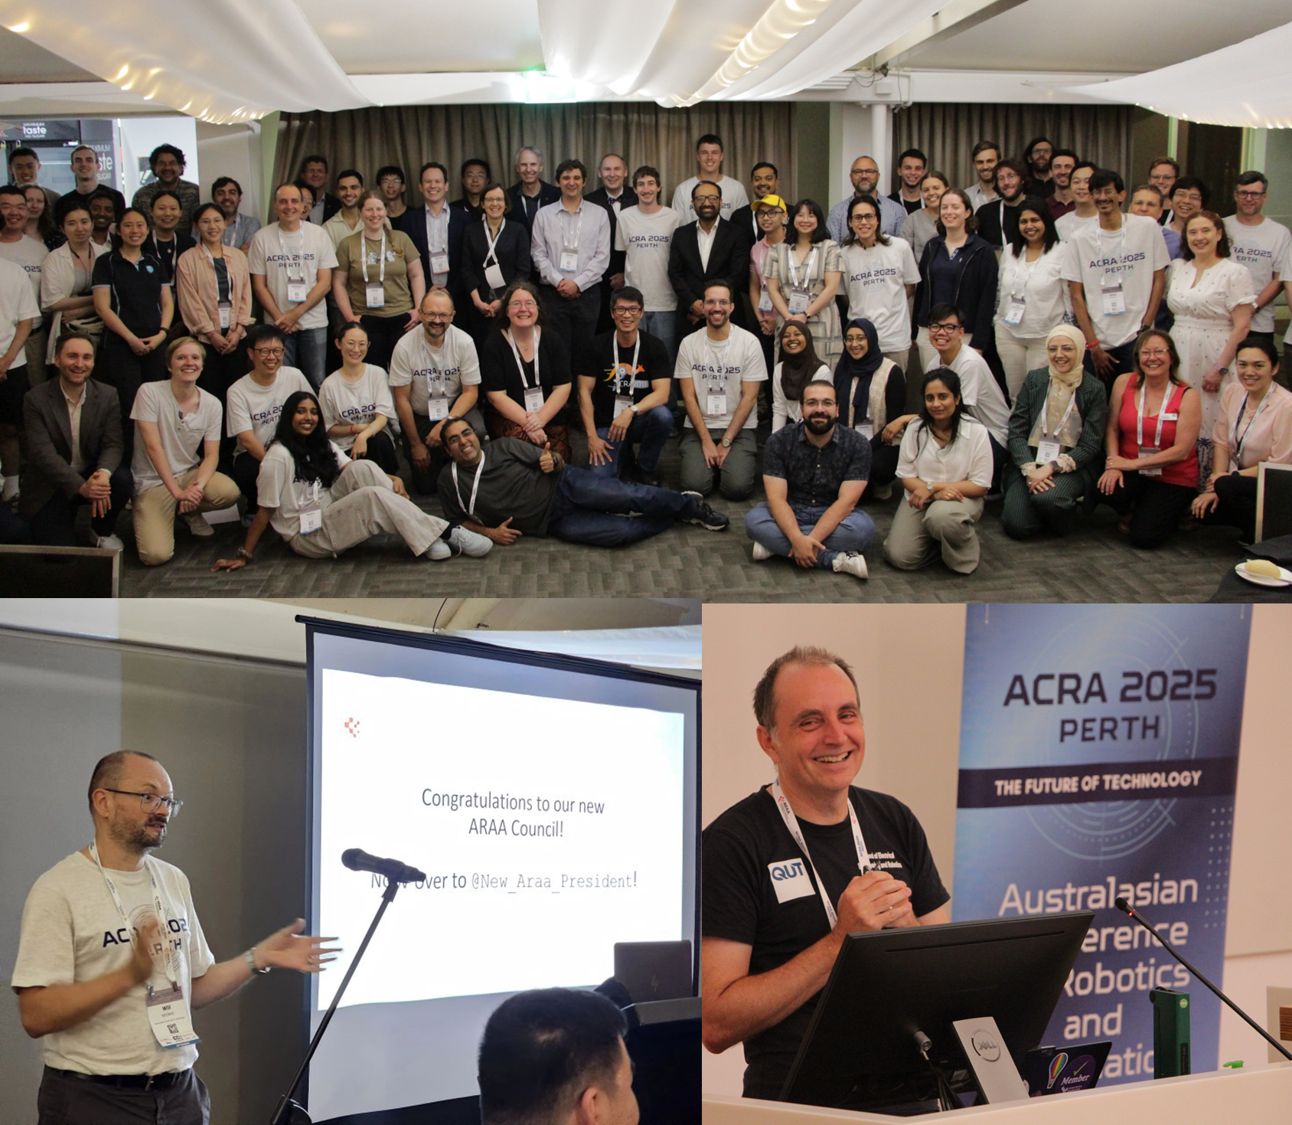
The 27th Australian Conference on Robotics and Automation (ACRA) was held at Edith Cowan University in Western Australia from 1-3rd December, bringing together leading researchers and industry innovators. The Australian Cobotics Centre proudly contributed five accepted papers, highlighting advances in collaborative robotics, humanoid systems, and AI-driven decision-making:
- Solomonoff-Inspired Hypothesis Ranking with LLMs for Prediction Under Uncertainty
Authors: Josh Barber, Rourke Young, Cameron Coombe, Will Browne (QUT) - User Preference for Handle Force Transformation for Quadruped Guide Robot
Authors: Luke Bouttell, Marc Carmichael, Sarath Kodagoda (UTS) - Robots Watching Robots – Pose Estimation Applied to Humanoid Robots
Authors: James Matthew Young, Jonathan Roberts (QUT) - Big Robots, Small Tasks – Task Scale Reduction Using a Simple Pantograph Mechanism
Authors: Sean Burgess, Braydon Pithie, Jonathan Roberts (QUT) - Training Humanoid Robots to Walk in Lunar Gravity Using Reinforcement Learning
Authors: Benjamin Klein, Jonathan Roberts (QUT)
The conference concluded with a highlight for the Centre: Professor Will Browne was announced as the new President of the Australian Robotics and Automation (ARAA) Association.
Recent News
E.P.I.C. Experiences: From exploring human-robot interaction in Australian workplaces to leading robotics research in healthcare in Denmark.
Dr Stine Johansen joined the Australian Cobotics Centre in June 2022 as a Postdoctoral Research Fellow in the Human-Robot Interaction (HRI) Pr ...
E.P.I.C. Experiences: From collaborative robotics research to engineering education leadership
Dr Meriam Anushani Bibile joined the Australian Cobotics Centre in late 2022 as a Postdoctoral Research Fellow based at Swinburne University o ...
Humanoids, Embodied AI and the Blurring of Job Roles in Systems
Humanoids, Embodied AI and the Blurring of Job Roles in Systems Written by Dr Alan Burden, QUT, Postdoctoral Research Fellow in Designing Socio-Techn ...